You do not need a robot on your desk to discover whether robotics will grab your attention. With Microduck, a browser window is enough to begin: a little robotic duck waddles into view, responds to direction commands and invites you to experiment. There is no parcel to wait for and no physical motor to damage with a clumsy first attempt. That low barrier is what makes the free Microduck simulator so appealing.
For me, the attraction goes beyond watching a cute machine move around a screen. Things become interesting when playing produces a question. How does it keep its balance? Why does a movement work better from one position than another? What could transfer to a physical machine? The demo offers an approachable starting point without pretending to answer all of those questions at once.
In this article
Try Microduck for free: start with the official simulator
The place to begin is Pollen Robotics’ official Microduck simulator on Hugging Face. Open the page, allow the application to load its models, then select “Waddle in.” During our brief editorial check, the environment loaded and an arrow-key input moved the simulated duck. That verifies the browser entry point; it is not a long-term performance test or a hands-on review of the physical robot.
You do not have to order hardware or set up a local programming environment for this first visit. Do allow some time for loading, however. The page is bringing an interactive simulation onto your device, rather than simply playing a small video. An initially empty or motionless area does not necessarily mean you have done something wrong.
I would start on a computer with a keyboard and a reasonably large window. It is easier to watch the controls and the movement together. Leave the buying decision aside for now. After a few minutes, you will have a better idea of whether you enjoy driving the duck or want to understand the machinery beneath the experience.
The controls worth learning first
The official simulator documentation describes the following mapping. The project continues to evolve, so follow the current application’s instructions if a control changes.
| Action | Control |
|---|---|
| Move forward, backward and turn | Arrow keys or WASD |
| Kick with the left or right leg | Q / E, in leg mode |
| Sit and stand | R, in leg mode |
| Lower the beak toward the ground | G, in leg mode |
| Switch between legs and rollers | M |
| Toggle the following camera | C |
| Orbit and zoom the view | Drag and scroll |
| Reset the scene | Space |
Resist the temptation to try every command at once. Give a short directional input, release it and watch. You will learn more from that sequence than from frantic button pressing. If your keys only move the webpage, click into the simulator area first. Changing the camera helps you inspect movement, but a different viewpoint is not a new capability of the robot.
Three small exercises that make the demo more useful
First, practise deliberate starts and stops. Pick a visible point in the environment and approach it in short stages. Watch how the body and legs respond when you request movement and then release the control. Repeat the same route. The point is not to set a speed record; it is to connect what you ask for with what the simulated machine actually does.
Next, prepare an action instead of merely triggering it. Line the duck up with the ball before attempting a kick. Repeat from a slightly different position and compare the outcome. This gives you a useful question: was the movement unsuitable, or was the starting position already poor? A triggered kick does not, by itself, show that the robot found the ball and invented a football strategy.
Finally, compare the two movement modes. Switch to rollers and attempt a similar route. Compare how steering, stopping and the movement look to you, without turning your impressions into claims about measured hardware performance. Write down what changes. “I need more room to approach this point” is a more informative observation than simply declaring one mode better.
These are editorial suggestions, not standardised benchmarks. For a class or robotics club, I would give everyone the same starting arrangement and the same task. That makes it easier to discuss genuine differences in approach, rather than accidentally comparing unrelated moments on different screens.
What is running underneath the duck?
According to the project documentation, a WebAssembly version of MuJoCo handles the physics, while ONNX Runtime Web executes pretrained movement models. The stated control frequency is 50 hertz. That refers to repeated control calculations, not 50 newly learned skills every second, and it does not promise an identical graphics frame rate on every computer.
A movement model of this kind is often called a policy. In simple terms, it maps the information it receives about the current state into actions. You supply the intended direction, while the model produces the movements it was designed to perform. That distinction matters: a person can choose the goal while a learned controller handles the motion.
The same distinction applies to much larger robots. A demonstration does not have to be either entirely remote-controlled or entirely autonomous. There are many layers between those extremes. Our article on Microduck as a physical-AI development platform looks more closely at the real product and its technical context.
Playing with a policy is not the same as training one
Driving around the ball ten times does not automatically train a new walking model. At this stage, you are using existing behaviour. Developing a new movement is another workflow: define the task, optimise a model and then evaluate the result. Keeping those steps separate prevents the common assumption that every interaction with AI immediately changes its underlying abilities.
The official microduck_rl project provides training environments built on mjlab. It describes PPO as the learning method, ONNX export and a CUDA GPU requirement for the documented local training route. It also points to Hugging Face Jobs as an alternative. Access to that compute should not be confused with trying the free browser demonstration.
I would approach this in three stages: move, understand, then modify. Trying to solve driver installation, training settings and a hardware purchase during the first visit only raises the barrier. A specific question is a better next step. Would you like the duck to stop more reliably, learn a different movement or respond to a particular situation?
That question also helps separate learning goals from shopping excitement. Someone who wants to understand feedback may already have plenty to explore. Someone who wants to deploy a modified policy will need a deeper technical plan. Neither route is made less worthwhile by starting with a modest experiment.
A successful simulation is not a hardware guarantee
A simulator represents selected properties of the world; it is not the world itself. A physical floor can yield differently, contact conditions can vary, components can have mechanical play and a battery changes state during use. A convincing screen demonstration is therefore a useful development step, not a substitute for controlled trials with the actual machine.
The local Microduck simulation documentation makes one boundary particularly clear. Parts of the real control software can operate against a simulated body, but that does not test absent physical drivers and devices, such as the real motor bus or radio. This local development environment should also not be treated as interchangeable with the approachable browser playground.
For a buying decision, the browser leaves out very practical experiences: motor noise, physical feel, actual battery life, maintenance and behaviour on your own carpet. Nor does an engaging appearance prove that the machine has human feelings. Our article on robot pets and emotional attachment explores why we can nevertheless be quick to give machines a personality.
The real robot: price, purpose and the meaning of open source
Pollen Robotics’ product page describes Microduck as an approximately 25-centimetre-tall biped with 15 motors. It lists an introductory preorder price of $399 before taxes and shipping. That is not a universal delivered price. Check the current store information for your country, accessories and delivery expectations; using the simulator does not require a purchase.
Another distinction is worth keeping. The official press kit says the open-source statement covers the software stack, not the mechanical and electronic design files. It should therefore not be read as a promise that every part of the physical product is supplied as an openly reproducible construction plan.
To me, the fair question is not whether Microduck has already become a useful household worker. It is whether a platform for play, understanding and development matches what you want to do. The Alpha Bionic robotics company directory offers context on manufacturers with different priorities. Curiosity alone is enough reason to begin in the simulator; a preorder does not have to be your admission ticket.
If the simulator loads slowly or does not respond
Check the simple things first. Has loading finished? Is the play area active? Is the correct window receiving your keys? If the experience stutters, close other demanding tabs and try an up-to-date browser. A slow display alone says little about the quality of the movement model; the device and browser environment can also affect what you see.
Do not confuse local computation with a completely offline experience. The project also documents a networked display of other visitors. Before using it in a classroom, check access, school-network rules and the intended activity. A successful trial on one computer is not a guarantee that thirty other devices will behave identically.
My takeaway is simple: Microduck makes the first step refreshingly small. You can turn interest in a robot into an observation of your own, rather than only watching someone else demonstrate it. The most valuable moment is not the first waddle. It is the moment you want to explain why a movement succeeds. That is where the learning really starts.
Microduck simulator FAQ
Is the Microduck simulator free?
The official browser playground is free to access. The physical robot, accessories and any compute used for your own training are separate offerings.
Do I need programming experience?
Not to begin with the supplied controls. Training new policies or changing the software requires additional knowledge and a suitable development environment.
Does the duck learn new skills while I play?
The browser demo executes existing trained models. Steering it is not a new training run. Separate tools and workflows are provided for that work.
Can I use a game controller?
The official documentation describes gamepad inputs. Test your particular controller and browser combination before relying on it for a demonstration or lesson.
Will a simulated result work identically on the real robot?
Simulation supports development but does not replace hardware validation. Physical actuators, surfaces, sensors and other influences can introduce differences.
Is the robot in the article image invented?
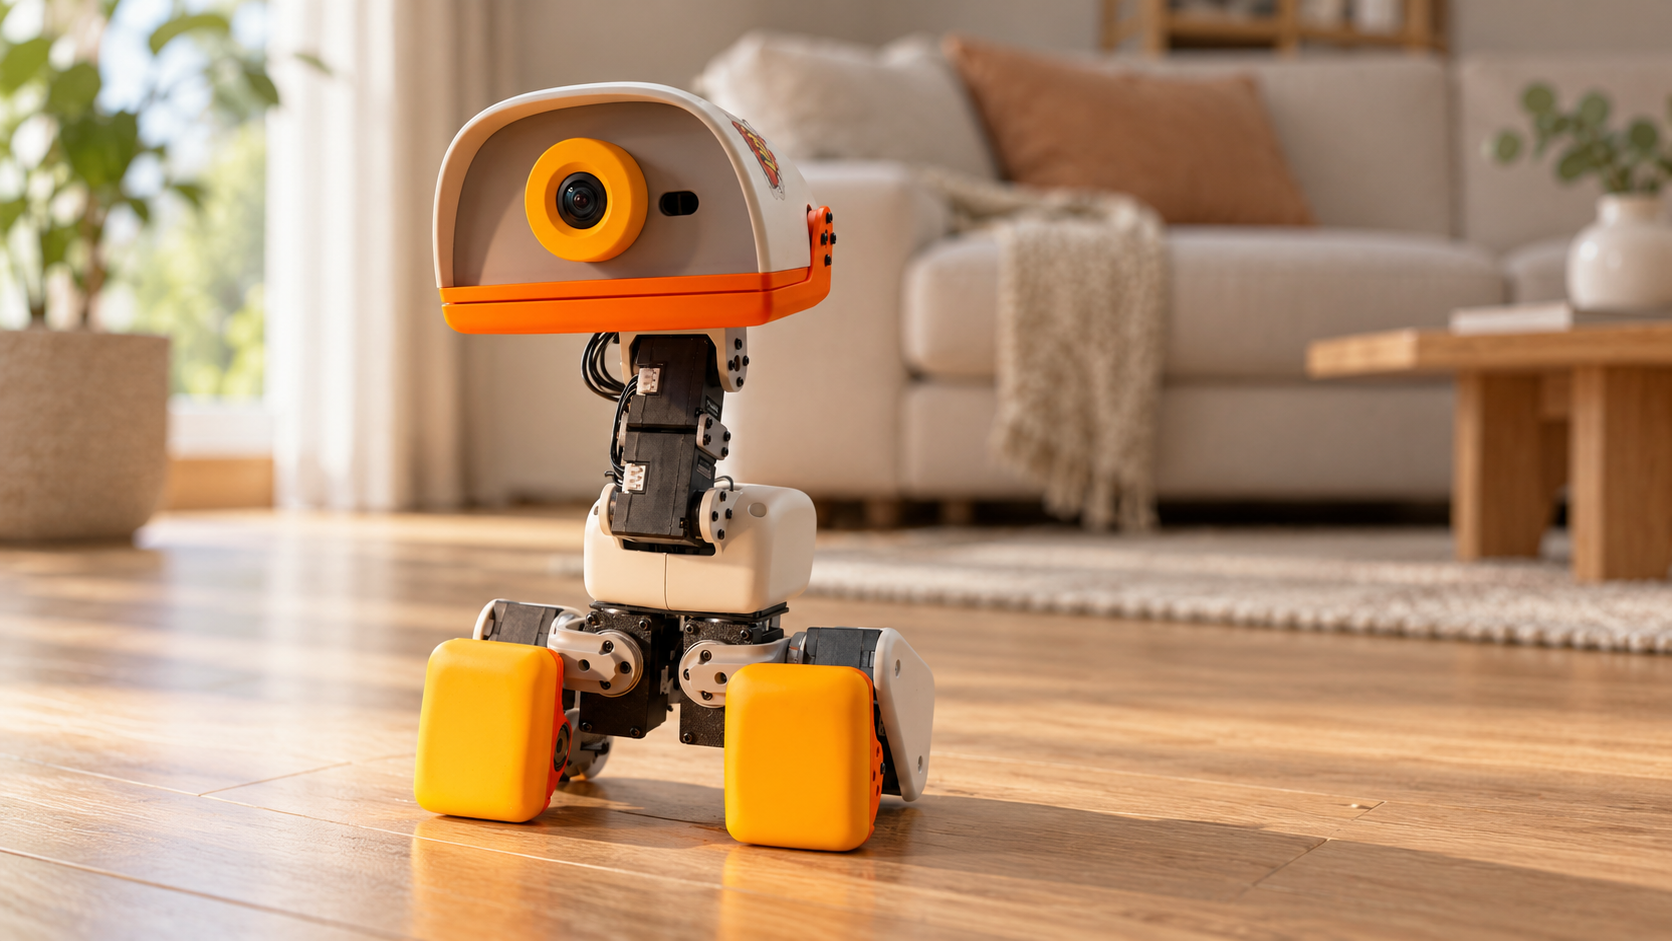
The image was created with AI using a manufacturer photograph of the real Microduck as a reference. It places the robot in a generated neutral living room. It is not an original photograph, simulator capture or documented hands-on test.
Image: Alpha Bionic. Reference-based AI illustration of Microduck using a Pollen Robotics / Hugging Face manufacturer photograph. Generated living-room scene; not an original photograph or hands-on test.
Author Nico Nuss has worked with mobile computing and automation software since 2001. His many years of experience and strong interest in emerging technologies shape his work on robotics and artificial intelligence.