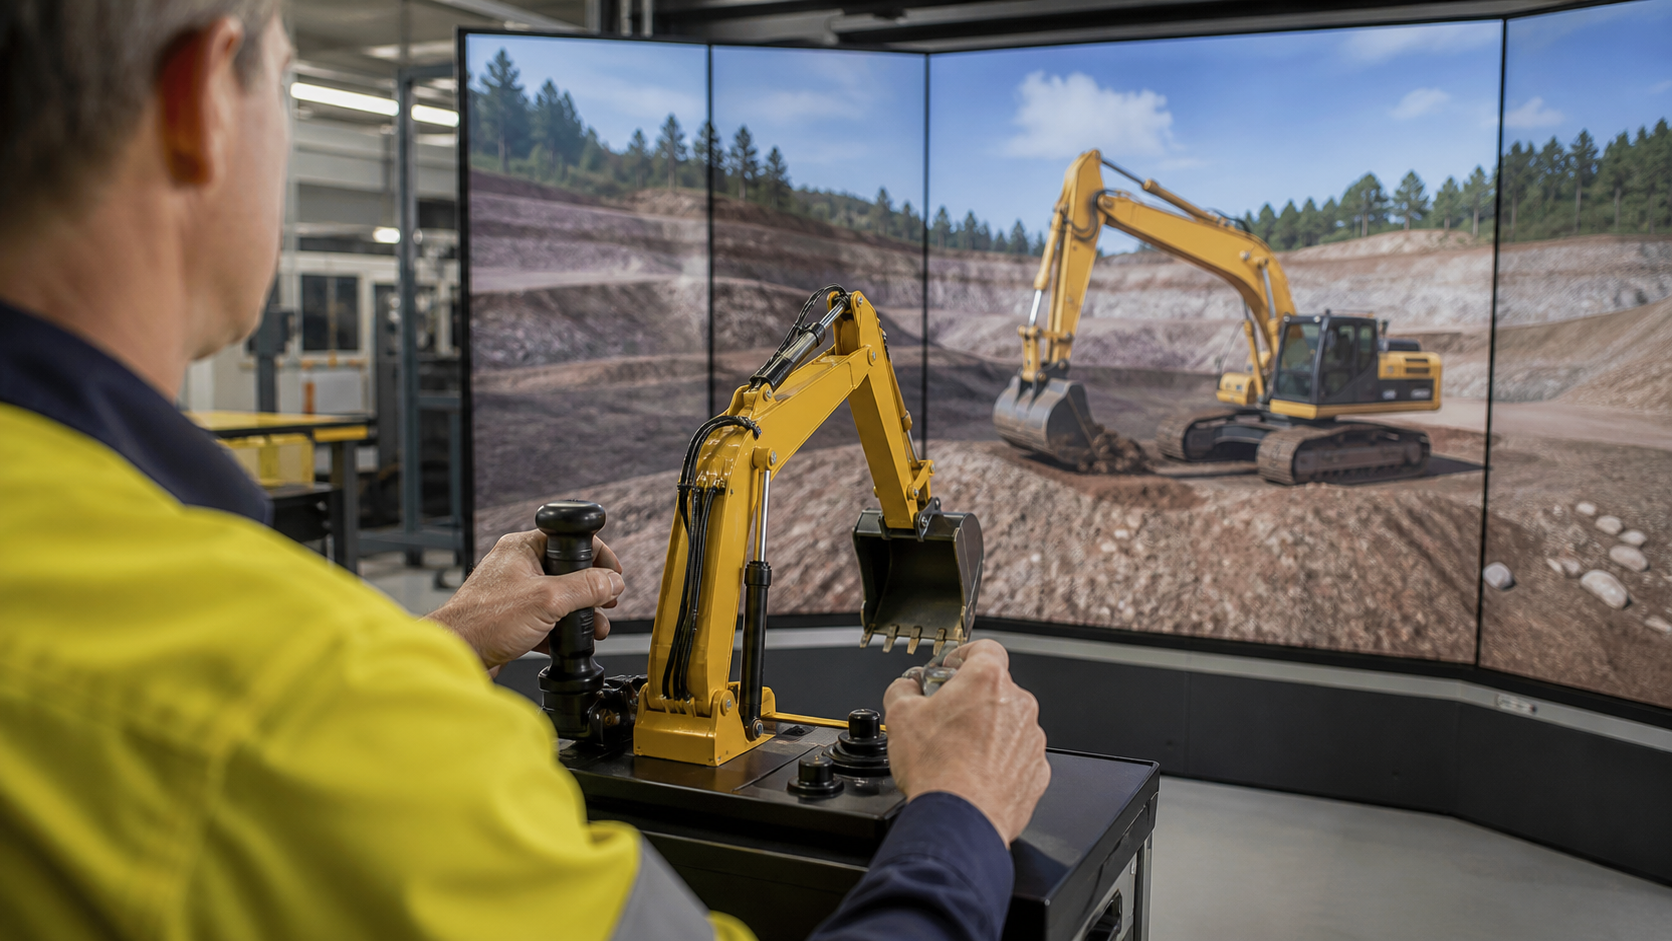
Excavator operators normally spend months building a mental map between several joystick movements and the machine’s boom, arm, bucket and cab. MIT and Sumitomo Heavy Industries have tested a more direct interface: move a miniature excavator arm, and the simulated machine mirrors the motion.
Replacing an abstract controller with a physical analogy
The researchers call the system the World-Space Interface, or WSI. Its small mechanical arm resembles the kinematic structure of an excavator. Instead of memorising which joystick combination produces a desired bucket path, an operator physically demonstrates the movement through the model.
A digital excavator displayed across six immersive screens responds to the input. The design turns a difficult translation problem into a form of embodied control: the human manipulates a representation of the machine rather than issuing abstract commands.
Novices performed like experts from the start
The team created 15 virtual environments representing construction sites, highways, forest roads, riverbanks, mining areas and urban settings. Tasks included digging and grading trenches, scooping material, clearing debris and breaking rocks.
Participants trained for one hour a day over seven days using either the WSI or a conventional joystick simulator. MIT reports that novices remained behind experts with the joystick system, although they improved. With the World-Space Interface, novices performed at an expert-comparable level from the beginning.
Teleoperation may be the nearer-term opportunity
The interface is relevant even without fully autonomous machinery. An operator could sit inside an excavator or work remotely from a protected control station. Remote operation is valuable in unstable construction zones, contaminated areas, disaster response, mines and other environments where exposure creates risk.
This illustrates an important Physical AI principle: progress does not always mean removing the human. A well-designed interface can combine human judgement and perception with the strength, reach and endurance of heavy machinery.
Haptics could close the remaining sensory gap
The current controller translates movement, but the researchers are working to add force feedback. If the miniature arm resists as the excavator lifts rock or dense soil, the operator could gain a more natural sense of load and contact.
That feedback is especially important for remote work. Vision alone can hide whether a bucket is stuck, slipping or overloaded. Haptics may help operators respond before a situation becomes inefficient or unsafe.
The limits of the current evidence
The results were produced in a simulator, not during full-scale field operation. Real excavators add vibration, latency, changing ground conditions, mechanical wear and safety consequences. The interface must therefore be validated on actual machines before claims about training time or productivity can be generalised.
The Alpha Bionic view
The WSI is a physical prompt for a large machine: show the system the desired motion instead of encoding it through an arbitrary control scheme. The same idea could influence cranes, mining equipment, rescue robots and other systems where human expertise remains essential.
Sources and transparency
- MIT News: a better controller for construction diggers (20 August 2026)
- Journal of Computing in Civil Engineering: World-Space Interface study (online 17 August 2026)
- Bioengineer: improved excavator controller (20 August 2026)
- NewsBytes: World-Space Interface coverage (21 August 2026)
Disclosure: The expert-comparable result refers to simulator performance. Real-machine productivity, fatigue and safety still require field validation.
![[Image content created with AI] Alpha Bionic [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/alpha-bionic-logo-bionic-flow-header-transparent.png)
![Operate an Excavator Like Your Own Arm: MIT Rethinks Heavy-Machine Control 1 [Image content created with AI] mit excavator world space interface [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/mit-excavator-world-space-interface.png)
![When Robots Read Handwritten Instructions: FANUC Brings Physical AI to the Factory Floor 2 [Image content created with AI] Generic yellow industrial robot uses a wrist camera above a bin of metal parts beside a handwritten work order and a digital twin monitor [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/fanuc-physical-ai-factory-16x9-1.png)
![Nearly Million for Physical AI: U.S. Factory Robotics Comes With a Workforce Mandate 3 [Image content created with AI] arm physical ai workforce en [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/arm-physical-ai-workforce-en.png)
![Caterpillar Brings Physical AI to the Jobsite: Why the Digital Twin Is Becoming the Operating Layer 4 [Image content created with AI] caterpillar fieldai en [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/caterpillar-fieldai-en.png)
![Physical AI Is Not a Robot Category: The Race Is Moving to Systems 5 [Image content created with AI] Verschiedene Robotersysteme arbeiten vernetzt in einer modernen Fabrik [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/physical-ai-systems-market-editorial.png)
![200 Cleaning Robots Across 25 Airports: The Integrator Becomes the Product 6 [Image content created with AI] Autonome Reinigungsroboter arbeiten koordiniert in einem Flughafen-Terminal [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/airport-cleaning-robot-fleet.jpg)
![Anthropic's MHS Connects AI Agents to Robots and Laboratory Hardware 7 [Image content created with AI] Standardisierte Schnittstelle verbindet KI-Agenten mit Laborgeräten und Robotern [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/anthropic-mhs-physical-ai.jpg)
![Inside the Humanoid Gym: How Schaeffler Is Training Robots for Factory Scale 8 [Image content created with AI] Humanoid robot training inside an industrial test cell [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/schaeffler-aeon-humanoid-gym.png)
![Claws Instead of a Runway: Ice Dart Lands on Moving Icebergs 9 [Image content created with AI] Field research drone gripping a steep iceberg [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/ice-dart-iceberg-drone.png)
![Show It Once: GEN-1.5 Introduces Physical Prompting for Robots 10 [Image content created with AI] Human demonstrates opening a jar while a robot imitates the task [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/gen-1-5-physical-prompting.png)
![100,000 GPUs for Humanoids: Why Figure Is Making a .5 Billion Compute Bet 11 [Image content created with AI] Generic humanoid robot stands at the entrance to a long aisle of liquid-cooled AI server racks [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/humanoid-ai-datacenter-100000-gpus-16x9-2.png)
![Why Real-World Robot Data Is Suddenly Worth a Billion Dollars 12 [Image content created with AI] Two robotic arms fold blue fabric while a human operator records manipulation data with tracking gloves [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/robot-training-data-teleoperation-16x9-2.png)