A small quadcopter called Ice Dart can land on steep, moving icebergs by combining shock-absorbing legs with retractable microspines inspired by animal claws. The mechanism turns landing from a flat-surface problem into a controlled act of gripping—and could let drones become quiet, long-duration sensor stations in the Arctic.
How Ice Dart holds onto ice
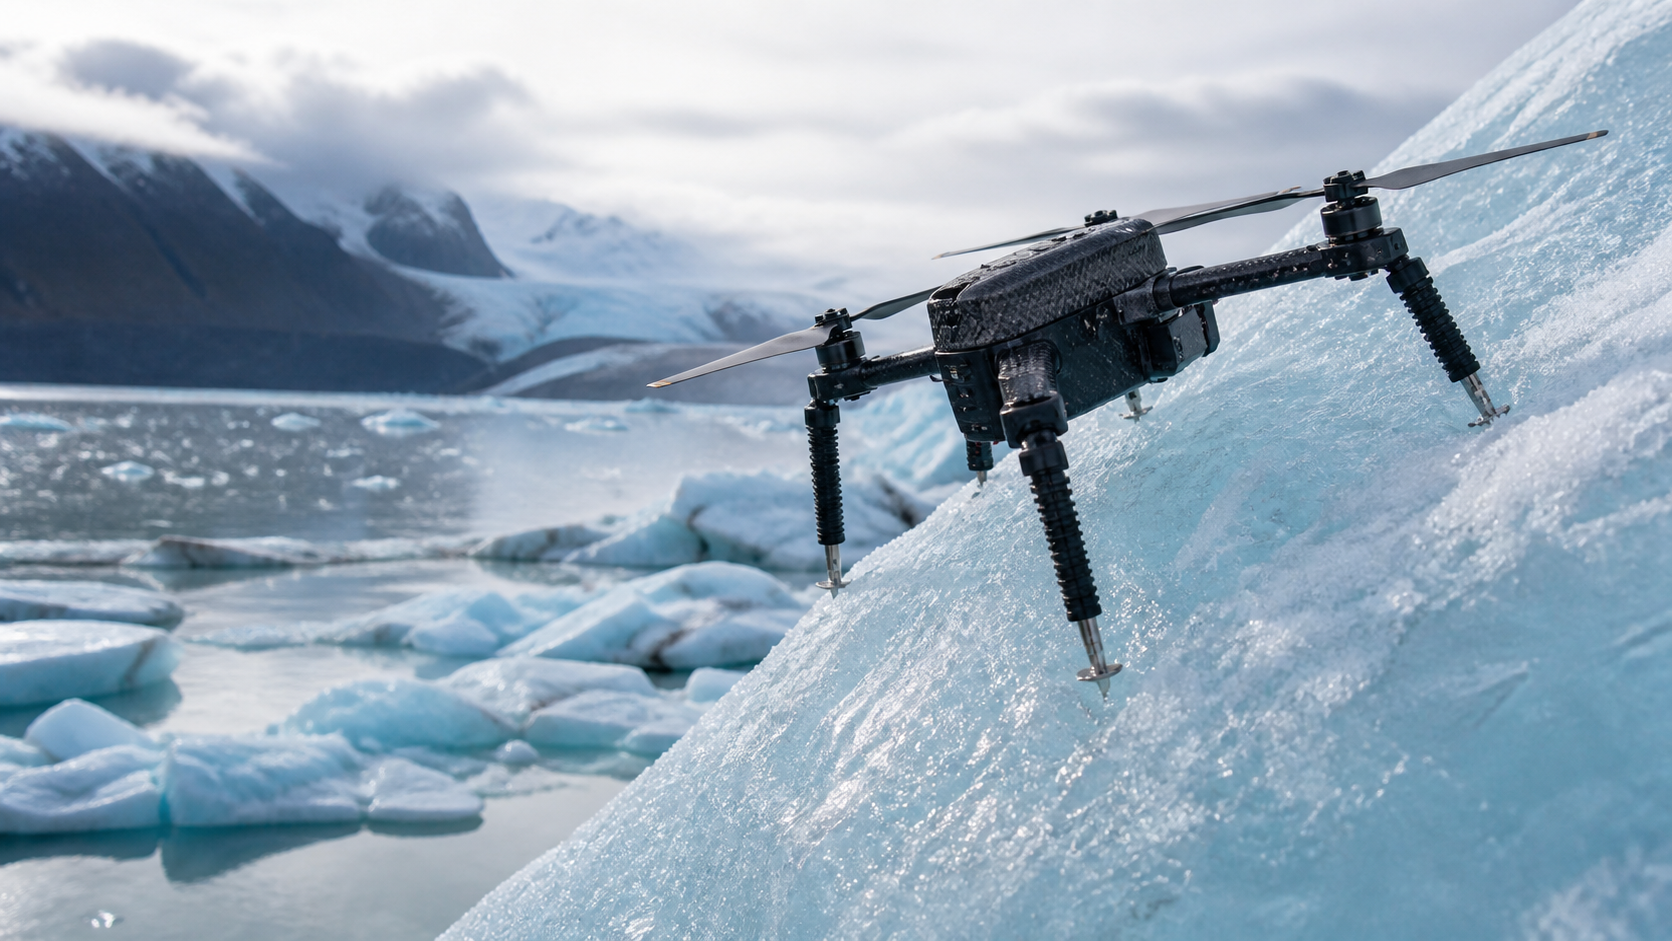
Ice Dart is a 2.65-kilogram carbon-fibre quadcopter developed for field robotics in icy environments. Four legs arranged in an X pattern pivot to adapt to the surface. Their suspension contains 38 friction disks that absorb impact, while each foot carries two retractable spines positioned for uphill and downhill loading.
The spines engage passively when the suspension compresses, a principle compared with the way a cat extends its claws under load. That passive mechanism matters in the field: it does not require a complex powered gripper to react within milliseconds during touchdown.
Field tests on glaciers and icebergs
Recent reports describe 24 landing trials in Icelandic glacier and iceberg environments. The research team reports successful landings on slopes up to 58 degrees, at touchdown speeds of up to three metres per second and in winds around 30 kilometres per hour. The reported success rate was 100 percent across this limited test series.
Those numbers are striking, but the sample remains small and the conditions do not cover every Arctic failure mode. The result should therefore be read as strong field validation of a mechanism, not as proof of unrestricted autonomous operation.
Why landing changes the mission
A hovering drone continuously spends energy simply to remain airborne. Once perched, Ice Dart can switch its main propulsion off and use only the power required by sensors, communications and onboard computing. That could extend observations from minutes toward days or longer, depending on payload and energy storage.
A landed platform is also quieter and has a lower thermal and radio-frequency signature than a hovering aircraft. Potential missions include measuring iceberg motion, local weather, melting processes and acoustic or seismic signals. Multiple low-cost systems could form a distributed monitoring network in places where fixed stations are difficult to install.
Bionics as mechanical intelligence
The project illustrates a practical form of bionics. The claw analogy is not decorative: it moves part of the control problem into the mechanics. Suspension compliance absorbs uncertainty in the touchdown, while the microspines convert load into grip. The drone needs less perfectly timed active control because the structure itself responds to contact.
This is a recurring principle in field robotics. Robustness often comes not from a larger AI model alone, but from combining perception and control with hardware that naturally tolerates uneven terrain.
Open problems before routine Arctic use
The most difficult steps now move beyond the foot. A deployed system must select a safe landing site autonomously, recognize fractures and unstable ice, maintain communications with tilted antennas and execute an emergency take-off if an iceberg rolls or breaks. Long-term icing, corrosion and repeated shock loading also require evidence.
IEEE Spectrum reported a planned Canadian Arctic deployment in August 2026. Data from longer missions will be more informative than another short landing video: the real question is whether Ice Dart can remain attached, collect useful measurements and leave safely as the surface changes.
Sources and transparency
- IEEE Spectrum: Arctic iceberg drones (18 August 2026)
- IEEE Transactions on Field Robotics: research paper (2026)
- ChosunBiz science report (19 August 2026)
- Researcher video and discussion on DIY Drones (20 August 2026)
Disclosure: The 100 percent figure refers to 24 reported trials, not unlimited operating conditions. Some performance details are reported by the research team and recent coverage.
![[Image content created with AI] Alpha Bionic [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/alpha-bionic-logo-bionic-flow-header-transparent.png)
![Claws Instead of a Runway: Ice Dart Lands on Moving Icebergs 1 [Image content created with AI] Field research drone gripping a steep iceberg [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/ice-dart-iceberg-drone.png)
![When Robots Read Handwritten Instructions: FANUC Brings Physical AI to the Factory Floor 2 [Image content created with AI] Generic yellow industrial robot uses a wrist camera above a bin of metal parts beside a handwritten work order and a digital twin monitor [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/fanuc-physical-ai-factory-16x9-1.png)
![Physical AI Is Not a Robot Category: The Race Is Moving to Systems 3 [Image content created with AI] Verschiedene Robotersysteme arbeiten vernetzt in einer modernen Fabrik [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/physical-ai-systems-market-editorial.png)
![Anthropic's MHS Connects AI Agents to Robots and Laboratory Hardware 4 [Image content created with AI] Standardisierte Schnittstelle verbindet KI-Agenten mit Laborgeräten und Robotern [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/anthropic-mhs-physical-ai.jpg)
![Up to 100 Billion Won for South Korea’s Human-Centered Physical AI 5 [Image content created with AI] snu physical ai lab [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/snu-physical-ai-lab.png)
![Operate an Excavator Like Your Own Arm: MIT Rethinks Heavy-Machine Control 6 [Image content created with AI] mit excavator world space interface [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/mit-excavator-world-space-interface.png)
![Inside the Humanoid Gym: How Schaeffler Is Training Robots for Factory Scale 7 [Image content created with AI] Humanoid robot training inside an industrial test cell [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/schaeffler-aeon-humanoid-gym.png)
![Show It Once: GEN-1.5 Introduces Physical Prompting for Robots 8 [Image content created with AI] Human demonstrates opening a jar while a robot imitates the task [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/gen-1-5-physical-prompting.png)
![Humanoids Learn Soccer Directly From Vision – Why It Matters Beyond the Game 9 [Image content created with AI] Humanoid robot learning reactive soccer from onboard vision [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/vision-driven-humanoid-soccer.png)
![Robot Grippers: Types, Selection, Grip Force & Cost 10 [Image content created with AI] Robotergreifer im Vergleich: Parallelgreifer, Vakuumgreifer, Magnetgreifer und Softgreifer in einer modernen Roboterzelle [Bildinhalt mit KI erstellt] [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/08/robotergreifer-auswahl-featured-16x9-1.png)
![100,000 GPUs for Humanoids: Why Figure Is Making a .5 Billion Compute Bet 11 [Image content created with AI] Generic humanoid robot stands at the entrance to a long aisle of liquid-cooled AI server racks [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/humanoid-ai-datacenter-100000-gpus-16x9-2.png)
![Why Real-World Robot Data Is Suddenly Worth a Billion Dollars 12 [Image content created with AI] Two robotic arms fold blue fabric while a human operator records manipulation data with tracking gloves [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/robot-training-data-teleoperation-16x9-2.png)
![Caterpillar Brings Physical AI to the Jobsite: Why the Digital Twin Is Becoming the Operating Layer 13 [Image content created with AI] caterpillar fieldai en [Image content created with AI]](https://alpha-bionic.info/wp-content/uploads/2026/09/caterpillar-fieldai-en.png)