Nvidia introduced a safety platform on September 28, 2026 that is designed to give autonomous AI agents and robots technically enforceable boundaries. Instead of relying only on a model to obey written instructions, the Open Agent Safety Platform separates an agent’s decisions from the controls governing what it may access. Gecko Robotics is exploring the approach for industrial inspection robots, turning an abstract AI-safety debate into a practical question for machines that can move through and act on physical facilities.
In this article
What Nvidia actually announced
The platform has two layers. OpenShell is an open-source runtime in which an AI agent may access only approved files, networks, tools and credentials. Those rules are enforced outside the agent process, so they cannot simply be rewritten or ignored through a prompt.
The second layer is called Sentry. Nvidia describes it as a reference design for independent monitoring on BlueField-4 data-processing units. This separate hardware is intended to watch agent behavior and quarantine an agent within milliseconds when it moves beyond its defined authority. In Nvidia’s architecture, that watchdog sits outside both the agent and the host system on which the agent runs.
That separation matters in robotics. A language agent attempting an unauthorized file operation creates a digital security problem. A physical agent can also command motors, grippers or mobile platforms. Its mistakes may damage equipment or put people at risk. Software permissions therefore cannot replace functional machine safety, but they can add another barrier.
Gecko Robotics brings the idea into the physical world
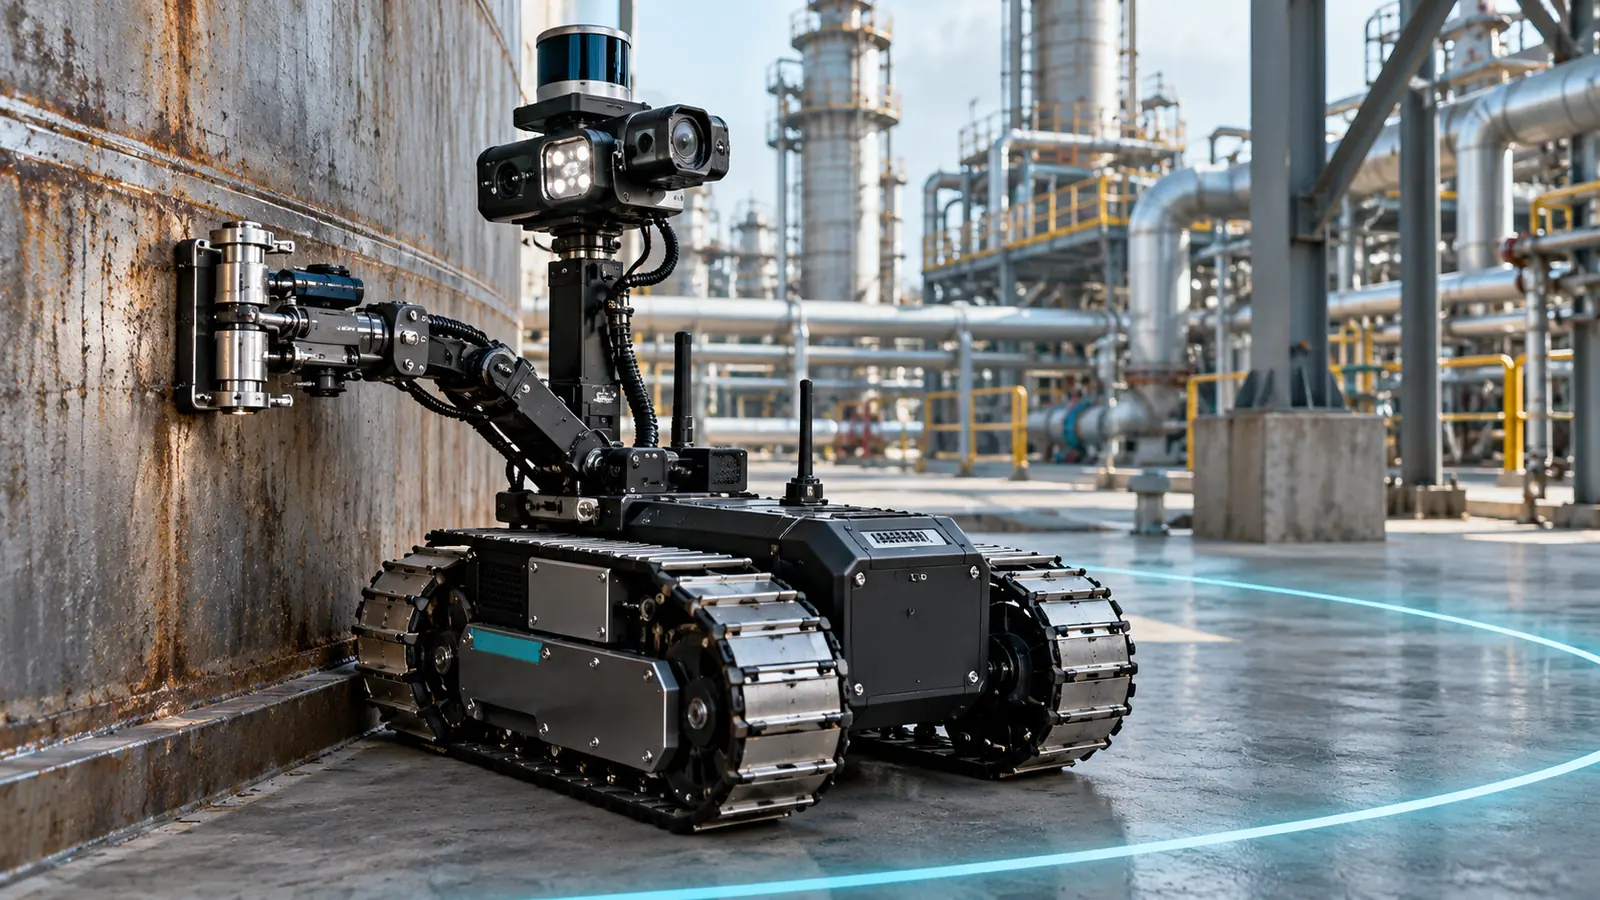
Gecko Robotics is among the companies examining OpenShell in a robotics setting. It develops inspection systems for major industrial facilities. Its Komodo robot is intended for tasks on critical infrastructure where sensors collect data from surfaces and structural components.
According to Gecko, OpenShell could help define clear limits for increasingly autonomous operation. A robot might be allowed to read sensor data and calculate an inspection route, for example, while being blocked from altering maintenance records or leaving a defined operating area. The distinction is important: Gecko has announced collaboration and technical exploration. It has not published independently verified long-duration results, intervention rates or failure data.
Why a safety prompt is not enough
Modern robots are increasingly given open-ended objectives instead of a completely pre-programmed motion sequence. A system may be told to inspect a facility, plan its own subtasks and use several tools. As that freedom grows, testing every possible action in advance becomes more difficult.
An instruction such as “do not leave the approved folder” is not a hard security boundary. A model may misunderstand a situation, call a tool incorrectly or reach a different decision after unexpected input. OpenShell therefore uses a zero-trust approach: the agent’s intention is not decisive; an external policy is. Actions that are not allowed should be blocked technically.
The principle resembles protection layers already used in operating systems and data centers. The new aspect is its application to agents that execute long chains of actions and to robots whose decisions can change the physical environment.
What the platform does not solve
This is the most important limit of the announcement. Access control can stop an agent from using a prohibited interface. It cannot automatically determine whether a camera perception is wrong, whether a gripper applies too much force or whether a planned path is mechanically unsafe. Traditional safeguards remain necessary: emergency stops, speed and force limits, safety-rated controllers, protected zones, redundant sensing and an application-specific risk assessment.
Formal policies are only as effective as their definitions. A robot granted an excessively large operating area may obey every rule and still create danger. Permissions that are too narrow may block productive work. The practical challenge is to define authority that can be verified while still allowing the task to be completed.
The Alpha Bionic view: safety becomes system architecture
The central news is not simply that Nvidia released another AI-security tool. Responsibility is being redistributed. Safety is no longer treated only as a property of the model or its training. It is split across several independent layers: the model, agent runtime, operating system, network, hardware watchdog and the robot’s mechanical safety systems.
That architecture could matter to European industrial users because it makes responsibilities easier to inspect. An operator could define which systems a robot may reach, record attempted actions and separate permissions for different jobs. This may improve auditing, but it does not replace machinery compliance or proof that a specific application operates safely.
The next convincing step would be published testing on real robots. Which hazardous actions were reliably prevented? How often did the system block legitimate work? What happens during network loss, manipulated sensor input or failure of the monitoring hardware? Only such evidence can show whether a compelling architectural idea produces a measurable industrial safety benefit.
What matters next
Nvidia is moving the discussion from voluntary model behavior to technically enforced authority. That is a logical step for physical AI because an autonomous robot should not be its own safety inspector. The work with Gecko Robotics brings the concept closer to operational facilities, but it remains an integration under development rather than proven protection for unattended, continuous operation.
Sources
- Nvidia: Open Agent Safety Platform, September 28, 2026
- Nvidia Technical Blog: OpenShell and Sentry, September 28, 2026
- Gecko Robotics: Safety at the Edge, September 28, 2026
- Associated Press: How the platform works and its limits, September 28, 2026