The U.S. Army has presented five winners of its xTechHumanoid competition. Nine finalists demonstrated their technologies at Marine Corps Base Quantico on September 9 and 10, 2026, and the Army published its summary on September 28. The selection reveals less about an immediately deployable military robot than about the technical bottlenecks that must be solved before a humanoid can operate reliably in difficult environments.
In this article
Five winners, but only one complete humanoid
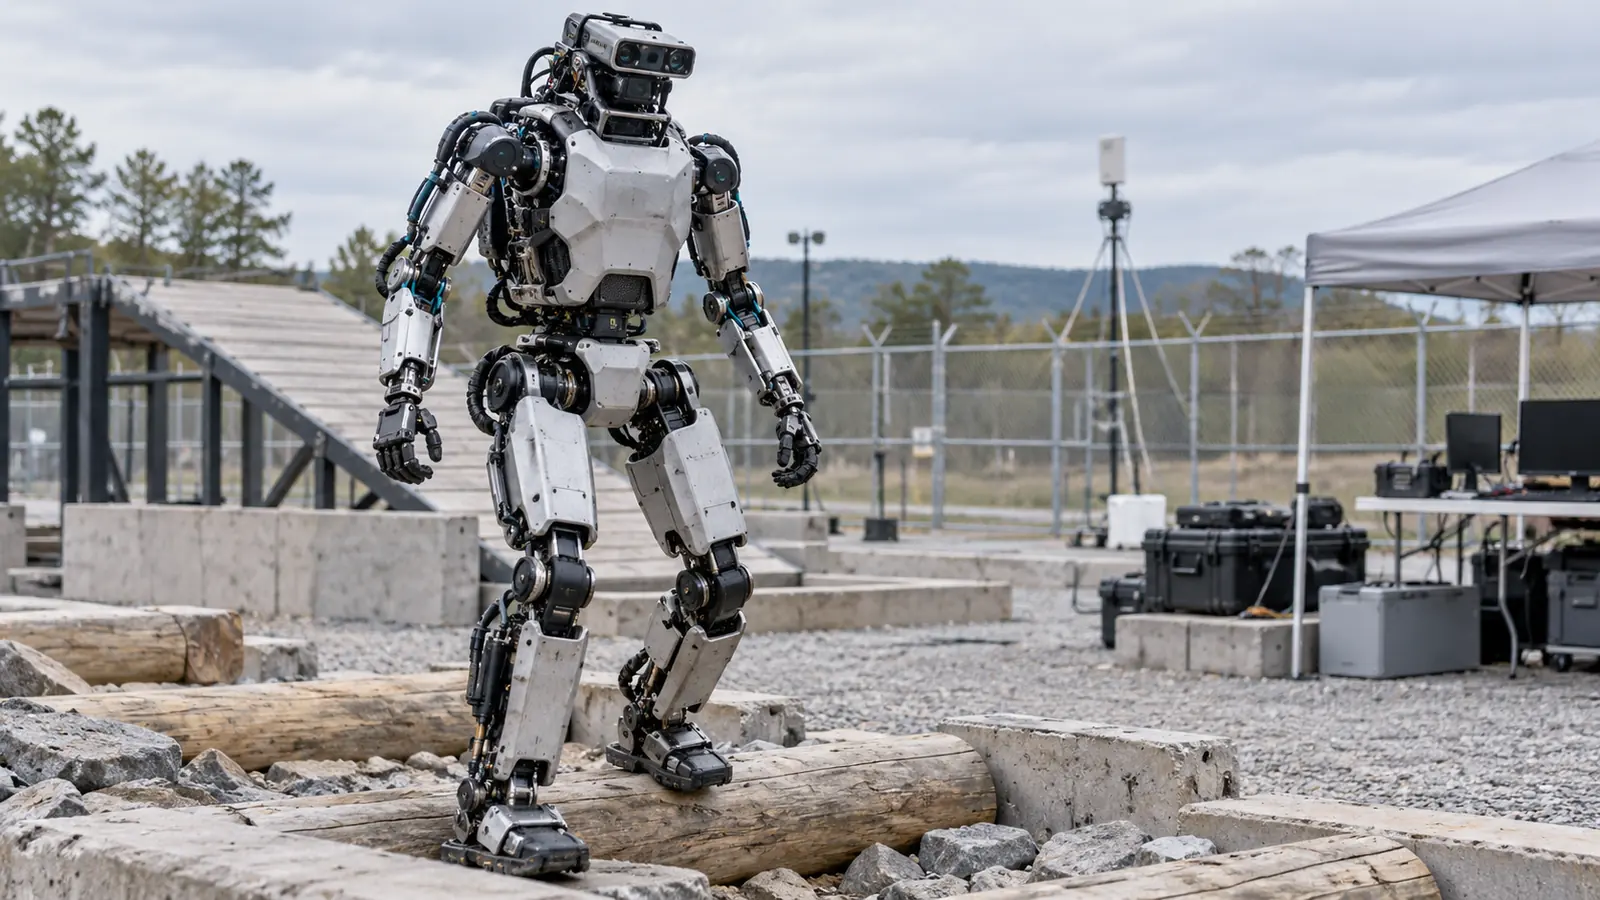
The competition began with 103 concept papers. Ten teams reached the final stage and nine demonstrated technology at Quantico. Among the five winners, only the Florida Institute for Human and Machine Cognition, or IHMC, supplied a complete baseline system. Its Alex robot combines impact-resilient actuators, protective components and a control architecture using both artificial intelligence and human input, according to the Army.
The other four awards went to technologies intended to make a humanoid practical. ACEs Group is developing scalable power and energy-storage systems. Hydroplane demonstrated a compact mobile power-generation unit. RAS Labs built sensitive fingertip sensors designed to detect force, shape and the beginning of object slip. Velocity Explorations connects command and situational information with discrete actions for robotic systems.
That composition is revealing. The Army did not choose five spectacular walking machines. It selected one complete robot and four building blocks for energy, perception and controlled execution.
What was evaluated at Quantico
The demonstrations were intended to confront commercial humanoid technology with military requirements. Army officials say technical experts and leaders observed the systems in a field-experiment setting. The objective was to understand their maturity and identify possible uses in dangerous or physically demanding work.
A competition final is not a troop deployment, however. The published material does not provide a standardized ranking, endurance results or comparative data for speed, reliability and operator workload. Nor does it show that any winner has been procured for operational service.
The program offered up to $490,000 in competition prizes. Individual winners may also be considered for follow-on agreements from a potential pool of up to $1.25 million. The word “potential” matters: selection creates an opportunity for more development, not a confirmed production order.
Why energy is a central constraint
Humanoid robots contain many powered joints and must continuously stabilize their own mass. That consumes energy even when a machine is standing or walking slowly. Large batteries are heavy. Additional storage extends operating time but also adds mass that the actuators must move again.
The presence of two energy-related winners makes this trade-off visible. Hydroplane says it demonstrated a compact hydrogen fuel-cell power unit outdoors. Its announcement does not establish whether the system meets all requirements for safety, logistics and rugged operation. The selection nevertheless shows that endurance and resupply may matter as much as impressive motion.
Why fingertip sensing and hybrid control matter
A humanoid cannot handle an object safely by knowing finger position alone. It also needs to sense force, detect slip and respond to changing shape. The tactile technology from RAS Labs targets that feedback. For tools, cables, valves and irregular objects, reliable touch may be more important than another increase in walking speed.
Control presents a similar issue. Full autonomy remains difficult to verify in unstructured, high-risk environments. IHMC therefore describes a hybrid architecture combining AI functions with human control. Velocity Explorations works at the command layer, translating trusted information and intent into limited, traceable robot actions.
The Alpha Bionic view: the winner list is a failure map
The competition’s real insight lies in the categories that were selected. They mark the points where humanoid systems may fail outside a prepared demonstration: inadequate endurance, vulnerable actuators, uncertain grasping and autonomy that is too broad or difficult to control.
Many of the same problems apply to civilian robots. A machine in a chemical plant, power station or disaster zone also needs dependable energy, robust joints, sensitive hands and clearly limited authority. Military requirements intensify these challenges, but they do not create entirely different ones.
That is why the announcement should not be framed as the beginning of a humanoid army. What is documented is a technology selection following demonstrations. What is not documented is a fleet order, continuous productive operation or suitability for a specific mission.
What would need to be proven next
A meaningful assessment would require operating duration, energy consumption, payload, fall-and-recovery data and the proportion of work performed through human teleoperation. Tests in rain, dust, damaged terrain and degraded communications would also matter. Only published results and actual follow-on awards would justify describing the program as a move toward field operation.
The xTechHumanoid winners do not demonstrate that military humanoids are ready for deployment. They show which technical building blocks the U.S. Army considers relevant for the next stage of development. That is less dramatic than a combat-robot narrative, but far more informative about the technology’s real maturity.
Sources
- U.S. Army PIT: xTechHumanoid winners, September 28, 2026
- Official xTechHumanoid competition page, winners announced September 11, 2026
- Hydroplane: winning power system, September 17, 2026