The cloud is easy to take for granted until a robot dives below the surface. GPS signals do not provide normal underwater positioning. Radio communication becomes severely constrained, light and visibility change quickly, and recovering a failed machine can be difficult. For physical AI, the underwater world is a particularly honest examination.
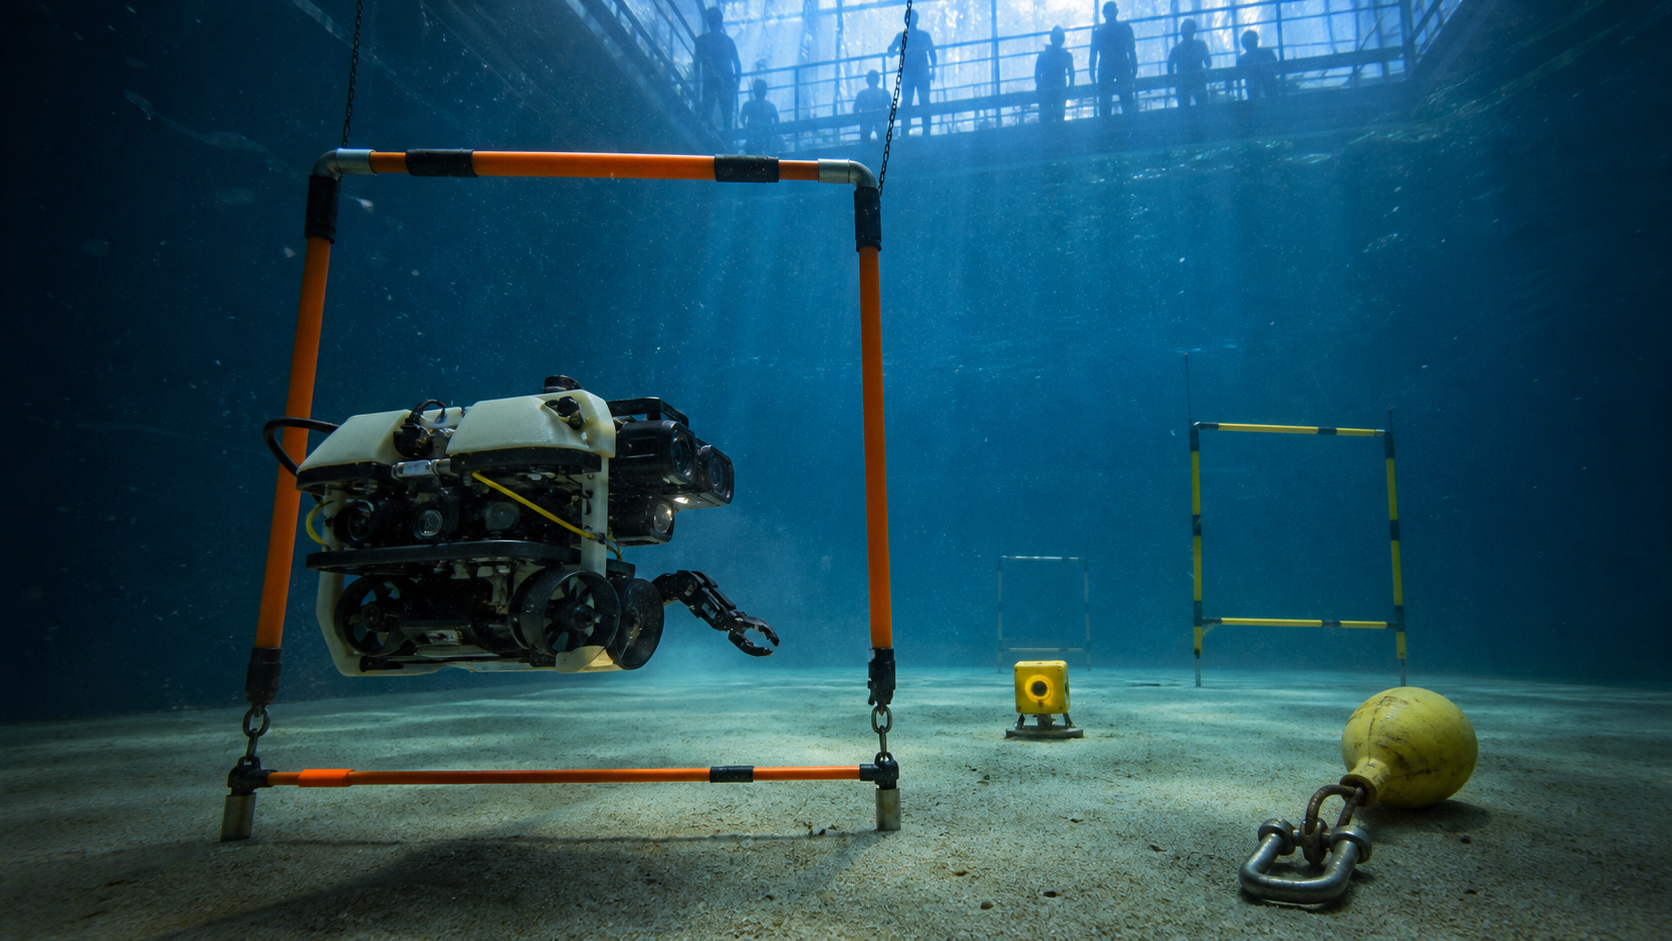
On 18 August, the German Research Center for Artificial Intelligence brought teams into its Maritime Exploration Hall in Bremen for an Underwater Robotics AI Challenge associated with IJCAI 2026. The tasks were easy to describe and hard to execute: navigate gates, detect and inspect an object, and retrieve a shackle attached to a buoy.
The challenge at a glance
- The test basin measures 23 by 19 metres and is eight metres deep.
- Vehicles had to find coloured gates whose positions could differ from the training data.
- Inspection combined visual detection with controlled close-range navigation.
- The manipulation task required locating an object, grasping it and bringing it to the surface.
The organizers accepted both autonomous underwater vehicles and remotely operated vehicles weighing no more than 20 kilograms. That distinction matters: remote control can demonstrate hardware capability, while autonomous runs test whether perception and decisions remain on the machine.
Why GPS disappears underwater
Satellite navigation depends on radio signals that travel well through the atmosphere but poorly through water. An underwater robot therefore has to estimate its position from other sources: inertial sensors, depth measurements, cameras, acoustic systems and knowledge of its own motion.
Every source drifts or becomes uncertain. Inertial estimates accumulate error. Cameras struggle in darkness, turbidity and scenes with few visual features. Acoustic measurements provide useful range or velocity information but usually with lower bandwidth and different failure modes from vision.
The result is sensor fusion under pressure. The robot must combine imperfect clues and maintain a useful estimate of where it is. An attractive path plan is worthless if the underlying position estimate is wrong.
Communication is an engineering constraint, not a minor inconvenience
A warehouse robot can often stream data over Wi-Fi and ask a remote system for help. Underwater communication is slower and less dependable. Acoustic links can cover distance, but they do not behave like broadband. Latency, interference and limited data rates force more processing and decision-making onto the vehicle.
This changes the meaning of autonomy. A marine robot needs a plan for silence: what to do when instructions stop, when its map becomes uncertain or when it cannot confirm that an operator received a message. Safe behavior may mean pausing, surfacing, returning to a known point or abandoning an object.
Why the coloured gates are not as simple as they look
Passing through an orange gate before a yellow one sounds like a classroom exercise. In the basin, the vehicle has to detect the structure, distinguish the colours under altered light, estimate the opening, align its body and compensate for water movement. The organizers also warned that the gate position would differ from the training data.
That last detail is essential. A system that memorizes a path can look competent in a familiar layout. Moving the target tests whether it actually perceives and replans. The same principle applies to robots on land: change the object, lighting or approach angle and watch whether the learned skill survives.
Manipulation exposes the full robotics stack
Retrieving the shackle combines navigation, perception and physical contact. The robot must approach without disturbing the target, understand the geometry, place a gripper accurately and account for forces that change as the object moves through water.
A failed grasp is not necessarily the most revealing failure. More important is whether the robot recognizes that the object was missed, decides to try again and avoids entangling itself in the rope. Recovery behavior separates a promising demonstration from a useful autonomous system.
Data scarcity makes the problem harder
Internet-scale image and text collections do not provide the kind of synchronized sensor, motion and contact data required for underwater work. Collecting new examples takes specialist equipment and test time. Conditions also vary between a clear research basin, a harbour, a lake and the open sea.
Simulation and synthetic data can expand coverage, but the gap between simulated and real water remains. Bubbles, suspended particles, changing currents, corrosion and biofouling create details that are expensive to model and difficult to ignore.
What the Bremen test can and cannot prove
A controlled basin is safer and more repeatable than the ocean. It is well suited to comparing methods and exposing basic integration failures. Success there does not automatically demonstrate readiness for deep-sea inspection, offshore maintenance or emergency missions.
Readers should therefore look for evidence beyond a winning run: repeated success, disclosed autonomy level, recovery after changed conditions and later trials outside the basin. The competition is a meaningful step precisely because it makes systems act in water, not only in simulation.
Bottom line
Underwater robotics strips away many conveniences of modern AI infrastructure. The robot cannot assume perfect positioning, permanent bandwidth or immediate human rescue.
That makes the field valuable far beyond marine applications. A machine that can perceive uncertainty, make decisions locally and recover when communication fails is learning the kind of autonomy that robots will need everywhere.
Sources
- DFKI, Underwater Robotics AI Challenge, 18 August 2026
- Robotics Institute Germany, Maritime Robotics showcase
- IJCAI 2026, official competition programme