A robot can look extraordinary for thirty seconds and still be unusable for an eight-hour shift. That gap between a successful demonstration and dependable work is becoming the defining engineering problem of physical AI.
The agenda at Actuate 2026 makes the shift unusually visible. Zipline is discussing why breaking robots is part of testing an autonomous fleet. Burro is drawing lessons from more than one million hours of outdoor autonomy. Cobot is addressing what it takes to put physical AI into production alongside people. These are different machines in different industries, but they point to the same conclusion: intelligence matters only when the hardware, software and operating process keep working together.
The important points
- Robot reliability cannot be inferred from a single successful video or benchmark run.
- Deliberate stress testing exposes weak components and recovery failures before customers encounter them.
- Large fleets generate rare failure cases that a laboratory may never reproduce in advance.
- Production readiness includes maintenance, observability, safe stopping and clear human escalation—not only model accuracy.
Why companies deliberately break robots
Testing to failure sounds wasteful until the cost of an uncontrolled failure is considered. A damaged prototype in a test facility is cheaper than a machine that stops inside a customer operation, blocks a route or behaves unpredictably near people.
Engineers therefore apply vibration, temperature changes, dust, impacts, communication loss and repeated mechanical cycles. They also create difficult software situations: incomplete sensor data, unexpected obstacles, timing errors and commands that cannot be completed safely. The goal is not to prove that failure never happens. It is to learn how the system fails, whether it detects the problem and whether it reaches a safe state.
This is particularly important for learned robot policies. A conventional automation cell usually works inside a tightly specified environment. A physical-AI system is expected to respond to more variation. That flexibility increases the number of situations that must be monitored and evaluated.
A million hours changes the kind of question engineers can ask
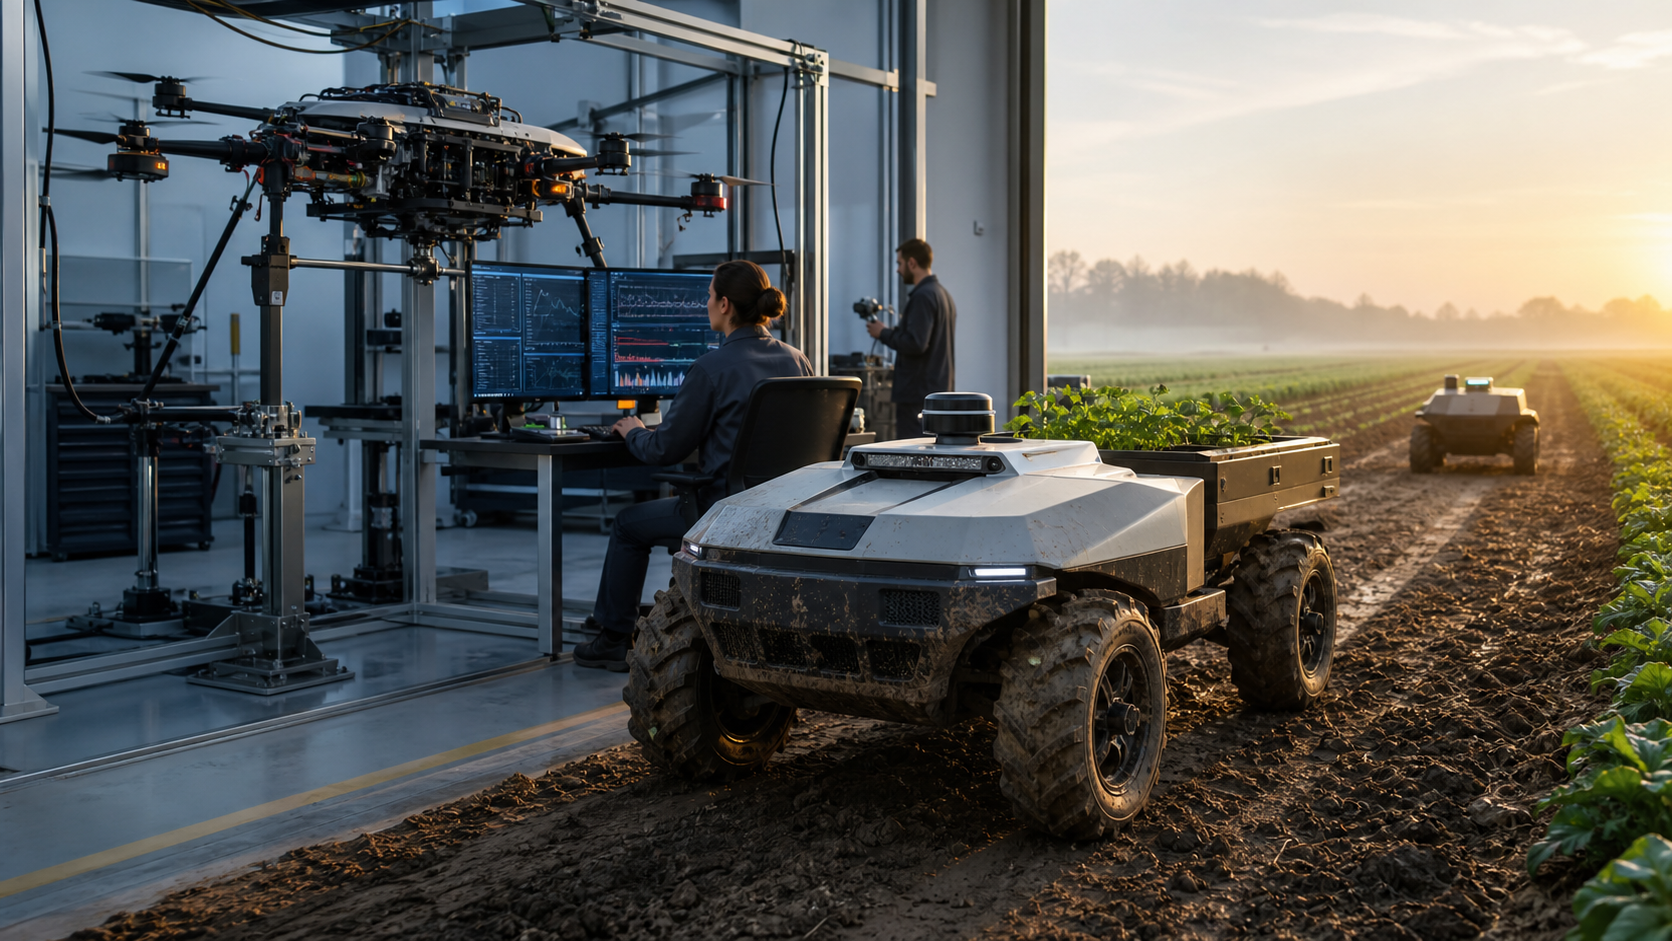
Burro says its deployed outdoor fleet has accumulated more than one million hours of autonomy. That figure does not prove that every hour was intervention-free, nor does it make one platform directly comparable with another. It does illustrate why field exposure becomes a competitive asset.
At large scale, teams begin to see the long tail: a particular reflection at sunset, mud packed around a wheel, a branch that resembles a barrier, a degraded connector or a positioning error that appears only after months of vibration. Each event can become a test case, a simulation scenario or a maintenance rule.
The useful metric is therefore not simply total operating time. Readers should look for intervention frequency, mission-completion rate, downtime, mean time between failures and the percentage of incidents that the system can resolve without a technician.
Why robot data infrastructure is becoming part of the machine
A production robot needs to explain what happened. That requires synchronized logs from cameras, lidar, joint sensors, software modules and operator actions. Without those records, an occasional failure can be almost impossible to reproduce.
Actuate’s emphasis on fleet operations, debugging, evaluation and the loop from field data back into development shows that robot infrastructure is no longer an afterthought. It is part of the product. Teams need to identify the relevant seconds in terabytes of data, protect sensitive information, reproduce the event and confirm that a fix does not create a different problem.
Reliability is more than stronger hardware
Mechanical durability is only one layer. A reliable robot also needs calibrated sensors, predictable latency, battery and thermal management, validated updates and a clear operating envelope. A model may choose the right action but receive a delayed image. A robust arm may still stop production if the fleet manager cannot distinguish a recoverable error from a safety-critical one.
Human procedures matter as well. Who can restart the robot? When must an operator intervene? How is a remote action recorded? How quickly can a worn component be replaced? Commercial availability depends on those ordinary questions as much as on artificial intelligence.
A better way to judge the next robot demonstration
Instead of asking whether a robot completed a task, ask how many attempts were made, what changed between runs and what happened after an error. A credible demonstration should disclose the level of autonomy, the duration of continuous operation and any human assistance.
The most impressive robot may no longer be the one with the most dramatic movement. It may be the machine that completes an uneventful shift, records its own anomalies and returns the next morning ready to work again.
Bottom line
The current robot boom is entering a less glamorous but more important phase. Companies are learning that production-grade physical AI is built through broken prototypes, carefully labeled failures and thousands of ordinary repetitions.
Reliability will not replace intelligence as a competitive advantage. It will determine whether that intelligence can leave the demonstration floor.
Sources
- NVIDIA at Actuate 2026, event programme for 18–19 August 2026
- Foxglove, Actuate 26 developer conference
- Burro, field-deployment and operating-hours background