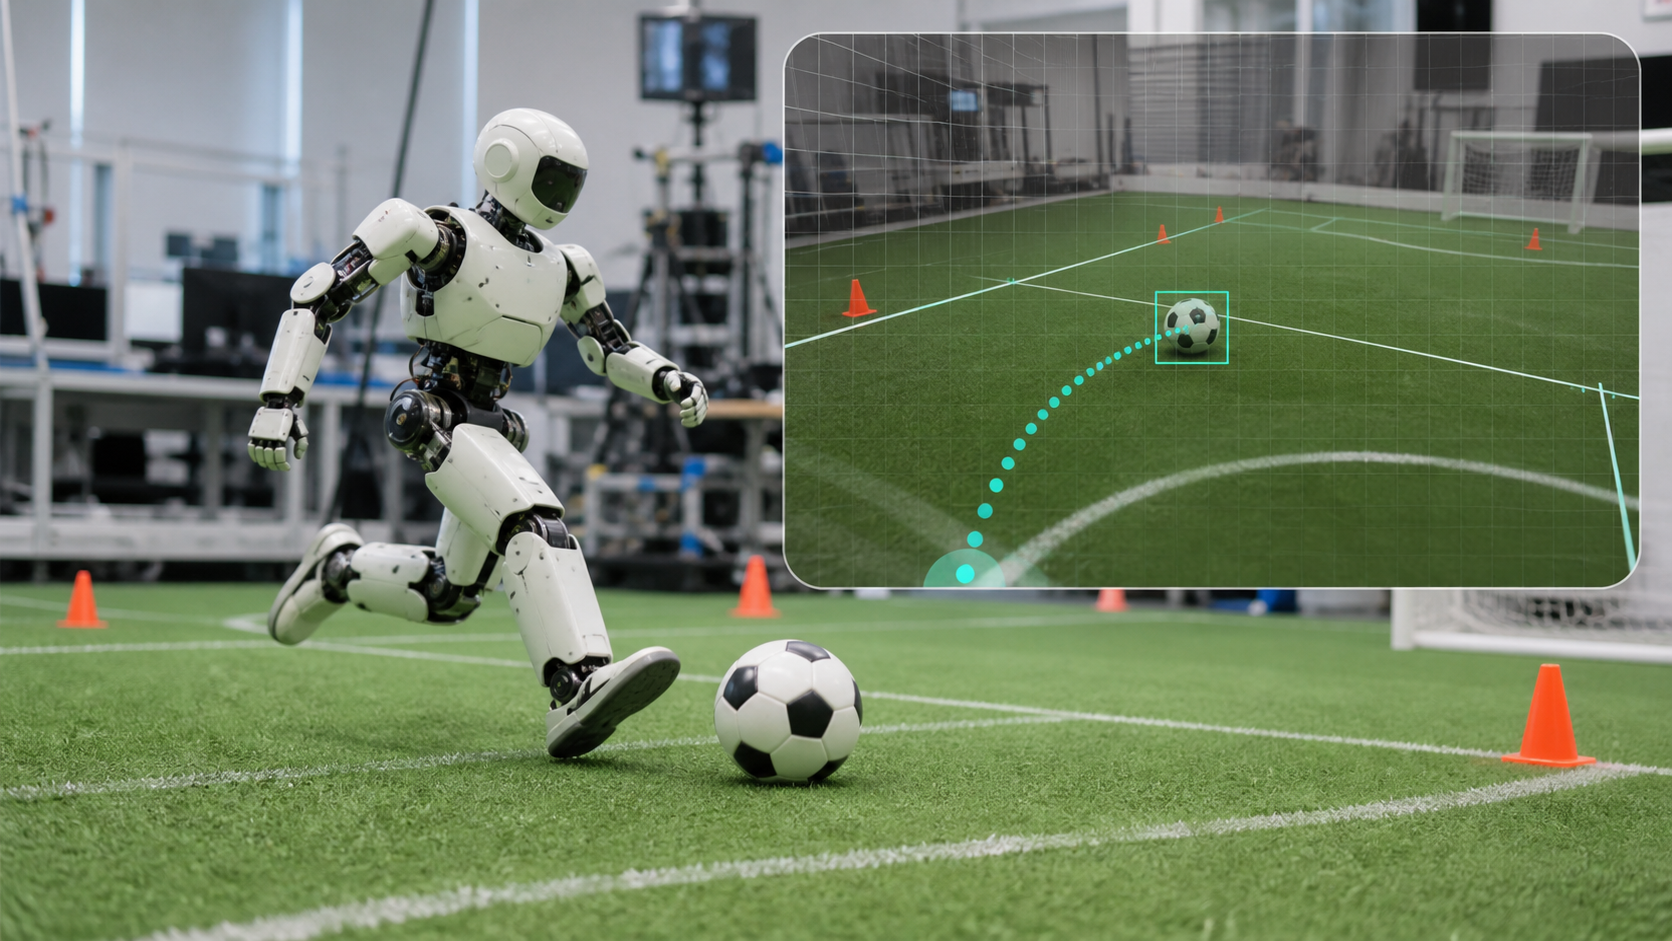
A humanoid robot that can search for a football, chase it and kick in several directions using only onboard vision is an engaging demonstration. The deeper significance is not football. It is the attempt to keep a physical machine useful when its perception is noisy, delayed or temporarily wrong.
A research team led by Yushi Wang and colleagues has presented a unified reinforcement-learning controller for vision-driven humanoid soccer. The updated paper, now referenced to Science Robotics, directly couples visual perception with locomotion control instead of treating perception, planning and movement as largely separate stages.
Why modular robot pipelines struggle
Many robots use a chain of modules. A camera system estimates where an object is, a planner selects a path and a controller turns that plan into motor commands. This structure is understandable and easier to inspect, but errors can accumulate between stages. A delayed ball estimate may send the planner toward a position where the ball no longer exists.
The new approach trains the controller to act with the imperfections of onboard vision already present. A virtual perception system simulates noise, detection failures and other limitations during training. The policy therefore learns not only how to move, but how to adapt movement when the visual estimate is uncertain.
What the researchers report
Using onboard vision, the robots learned behaviors including ball search, pursuit and multidirectional kicking. The authors report a 46 percent reduction in ball-position estimation error and up to a 64 percent reduction in time to kick compared with a rule-based baseline. In frontfield positions, the reported kicking success was around 90 percent.
These numbers are meaningful only within the published experimental conditions. They do not mean that the robot succeeds at 90 percent of arbitrary football situations or unfamiliar real-world tasks. Baseline choice, field geometry, lighting and opponent behavior all influence the result.
Why this matters outside football
Factories and service environments are filled with small deviations. A box is several centimeters away from its expected location. A person blocks part of a camera view. Lighting changes, an object moves or a sensor briefly fails. A robot that depends on a perfect world model may stop or make a poor correction.
Training a policy around perceptual uncertainty could help machines respond more smoothly to those deviations. Potential applications include mobile manipulation, warehouse picking and service robots that must approach moving objects. Football is valuable precisely because it compresses perception, balance, timing and contact into a fast, measurable task.
What remains unproven
A unified learned controller can be harder to diagnose than a modular system. When it fails, engineers need to determine whether the cause was perception, the learned representation or the resulting motion. Safety-critical applications may still require independent monitoring and deterministic stop conditions.
The research also does not demonstrate general intelligence. The controller was trained for a defined family of soccer behaviors, and successful transfer from simulation to real robots does not remove the need for task-specific training and validation.
The useful benchmark question
The next step is not simply a faster kick. Researchers should test performance under systematically changed lighting, camera blur, partial occlusion, moving obstacles and hardware variation. Reporting intervention rates and failure cases would make the system easier to compare with modular alternatives.
The most promising lesson is therefore modest but important: robots may become more robust when uncertainty is included in the control problem rather than cleaned up before the controller sees it.
Sources and transparency
The preprint first appeared in November 2025 and was substantially revised on August 20, 2026. The current news signal is the revised paper and its journal reference, not the first disclosure of the method.
- Learning Vision-Driven Reactive Soccer Skills for Humanoid Robots, revised August 20, 2026
- Science Robotics publication record
- Booster Robotics release, August 20, 2026