Two University of Stuttgart teams are developing ways for multiple robots to assemble building components together on a construction site. Announced on 6 October 2026, the EU-funded SCALAR and COBRAS projects have been awarded almost €8 million in total, according to the university. Work is scheduled to begin in November and run for three years. The announcement does not mean that a building has already been erected autonomously or that the systems are operating on a commercial site.
Construction is an unusually demanding setting for automation. Routes, lighting, stored materials and work zones change throughout a project. A useful robot system must therefore do more than repeat a precise movement. Transport, positioning, joining and worker safety have to function as one reliable process. Stuttgart’s two projects tackle that challenge in different ways.
In this article
SCALAR combines a crane with mobile robots
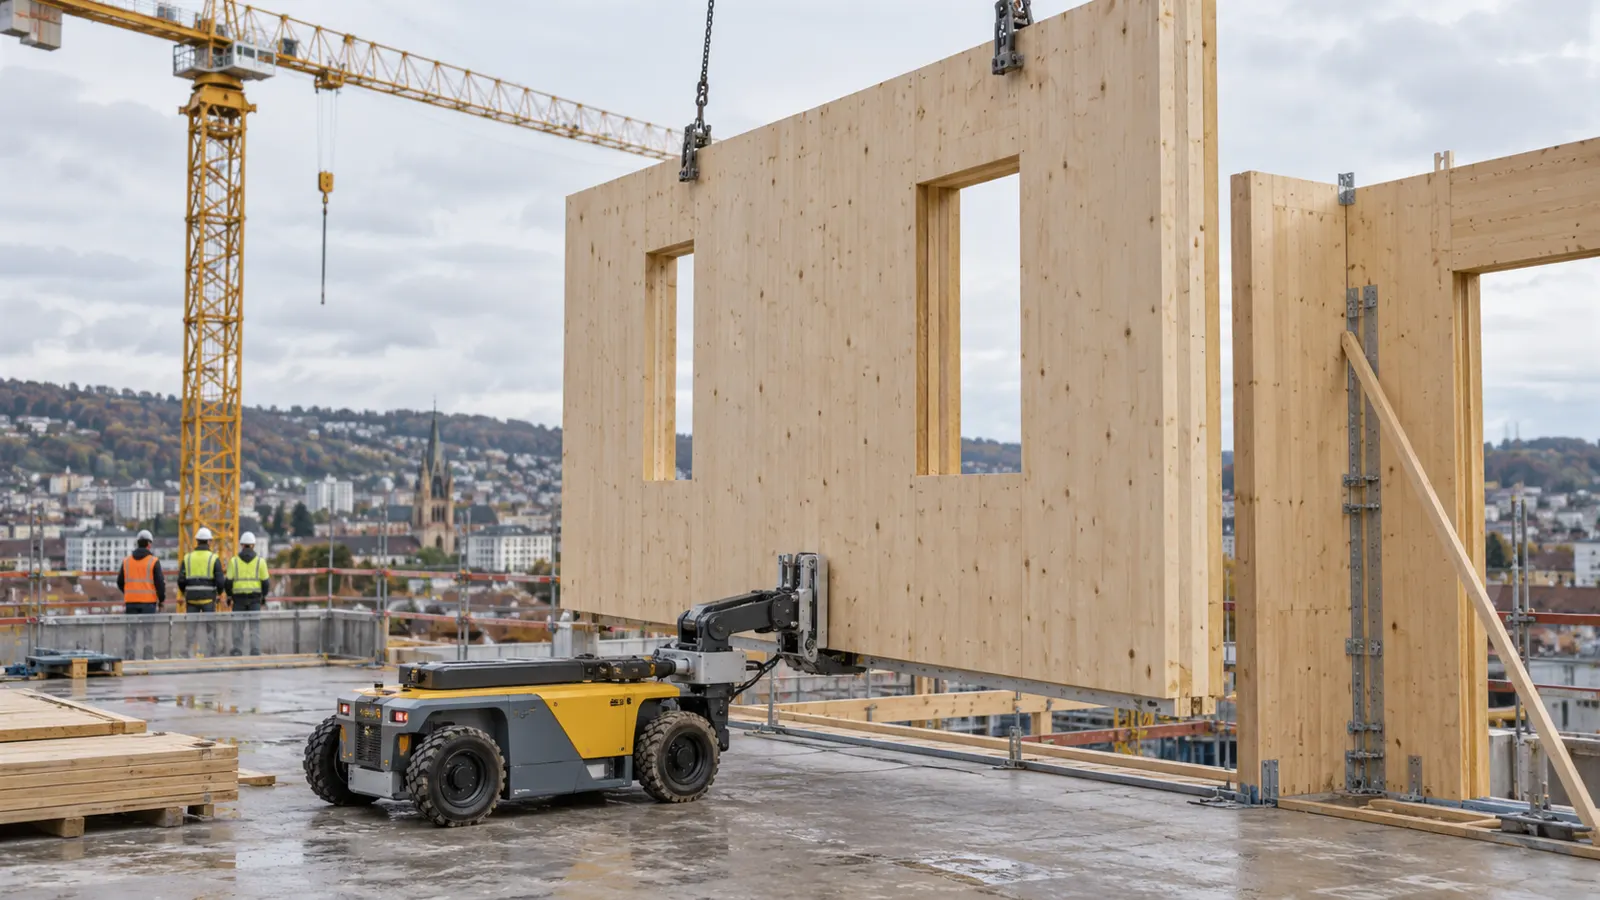
SCALAR—Multi-Scalar Robotic Construction for Autonomous On-Site Assembly of Modular Timber Structures—aims to develop both a timber building system with universal connectors and a matching robotic platform. According to the EU project record, retrofitted cranes would transport components and perform coarse positioning. Mobile robots and grippers would then align and mechanically connect them. The proposed applications include new construction, façade work and renovation.
The division of work is the technical point. A crane can carry a heavy wall panel but is not necessarily the best tool for the last few millimetres at a joint. A smaller robot may work accurately at the interface while the crane continues to support the load. The team plans to simulate assembly before building and coordinate the machines through a shared control system on site. That architecture is credible, but its reliability under real construction conditions remains to be demonstrated.
Integration may be the hardest part. Prefabricated timber modules still have dimensional tolerances. Their position can shift during transport. Sensors must identify edges and connection points in dust, rain or difficult light. A robot should not enter the joint area until the load, crane movement and human work zone are safe. These are practical tests for a future demonstration, not performance results that have already been published.
COBRAS designs the structure for a robot team
COBRAS takes another route. Its EU project record describes electrically powered mobile robots assembling and disassembling lightweight spatial structures from prefabricated elements. Several similar units would divide tasks among themselves. In principle, another unit could take over if one fails, and adding units could help with larger structures. The components themselves are to be designed for robotic handling and later reuse.
This is not merely a proposal to hand today’s construction work to a machine. The geometry of a component and the capabilities of a robot are developed together. Connectors must be reachable by a gripper. Each assembly step must leave the unfinished structure stable. Sensors must distinguish a properly seated part from one that only appears aligned. Reuse also matters: an automated assembly gains less if disassembly later damages the elements or requires extensive manual work.
“Swarm” should not be mistaken for a finished product. The EU record describes a target demonstration at technology readiness level 4 for COBRAS. That is validation of a technical setup at an early research stage, not proof of a market-ready system for changing customer sites. SCALAR likewise sets out to demonstrate a multi-storey timber section and a renovation case. Whether either approach works under the time and cost pressures of a live construction project is still unknown.
The evidence a real deployment would need
Builders will ask questions that a polished research video cannot answer. How long does setup take at a new site? How often must an operator intervene? What dimensional tolerances are acceptable? What happens when a connector is missing or a component is damaged? How do total costs change once the crane, robots, surveying, safety equipment and supervision are counted together?
The fair benchmark is the established process. Prefabricated timber modules are already installed with cranes and human assembly crews. A robotic system is not automatically better because it is autonomous. It would need to reduce installation time, take people away from hazardous handling, or make reusable construction more economical. Downtime, maintenance, training and the production of robot-compatible components would belong in the same calculation.
The projects are therefore significant research news, not evidence that a construction site has already been automated. Their common advance is a systems approach: purpose-designed parts and coordinated machines are being developed for a defined assembly task, rather than promising that one spectacular robot can build a house. The next decisive result would be a documented demonstration showing that transport, precise joining, human oversight and repeatability actually work together.
Sources
- University of Stuttgart: Robot teams for construction sites, 6 October 2026.
- European Commission/CORDIS: SCALAR, project record updated 10 June 2026.
- European Commission/CORDIS: COBRAS, project record updated 28 May 2026.