Humanoid robot hands are entering a practical contest: four fingers or five, tendons or joint-mounted motors, cameras or tactile sensors? A new Robot Uncut video compares Boston Dynamics Atlas, Tesla Optimus, Figure 03 and 1X NEO. Yet the crucial question is not which company quotes the largest degrees-of-freedom (DOF) number. It is which hand completes real work reliably, safely and with acceptable maintenance. Public manufacturer material does not yet provide a shared benchmark.
In this article
Humanoid robot hands compared: four design approaches
A degree of freedom is an independently controlled movement. Published totals are comparable only when companies count the same joints and describe the same hardware generation. For example, 1X includes three wrist DOF in its headline number. A DOF count alone says nothing about force feedback, grasp success, durability or repair time.
| Robot | Publicly described hand | Documented emphasis | Key missing evidence |
|---|---|---|---|
| Boston Dynamics Atlas | Four fingers, 13 DOF, direct joint actuation | Tactile sensing in fingers and palm; tool manipulation | Success rate and service life in extended use |
| Tesla Optimus | Five-finger designs; earlier tendon-driven versions | Several demonstrated development revisions | Current configuration and comparable performance data |
| Figure 03 | Five-finger hand with palm cameras | Fingertip sensors claimed to detect forces from 3 grams | Unambiguous current hand DOF and long-term results |
| 1X NEO | Tendon-driven hand, 25 DOF including three at the wrist | Force control, backdrivability and claimed IP68 rating | Independently confirmed whole-robot durability |
Atlas: why Boston Dynamics chose four fingers
Boston Dynamics describes the latest Atlas hand as having a thumb with four DOF and three other fingers with three each, for 13 in total. Its actuators sit at the joints rather than pulling remote tendons. Tactile sensors in the fingertips and palm detect changes in contact. The company discusses turning an object within the hand and holding a tool while operating its trigger as intended capabilities.
Leaving out a pinky is a deliberate trade-off. According to Boston Dynamics, a fifth finger would require three more actuators, more space and more possible failure points. That does not prove a four-finger hand is universally better; it shows how the company prioritizes the tasks it expects Atlas to perform. Our closer look at the Atlas hand explores that choice.
Tesla Optimus: the version problem
Tesla has shown several five-finger Optimus hands and discussed greater dexterity in its 2024 investor material. Earlier designs used tendon-like transmissions with motors in the forearm, as the video notes. But an older demonstration or patent cannot establish exactly how Tesla’s current intended production hand is constructed. A sufficiently detailed, public specification for a like-for-like comparison with the other current hands is missing.
It is equally important to separate a development demonstration from deployment evidence. A polished grasping clip does not reveal the number of attempts, failures or maintenance intervals. We cover the evolution of Tesla’s designs in our Optimus robot hands overview.
Figure 03: sensing at the point of contact
In its Figure 03 announcement, Figure says it placed a camera in each palm and developed fingertip sensors capable of detecting forces as low as three grams. A later Helix 02 demonstration describes control of a five-finger hand using these signals. Palm cameras matter when a head-mounted camera cannot see a partly hidden grip.
Figure’s public description does not, however, give a current hand DOF figure that can be compared cleanly with Atlas and NEO. Nor can one completed video task yield a statistically meaningful failure rate across unfamiliar objects or months of wear. The video also discusses Figure founder Brett Adcock’s change of view about his company’s tendon-based design. That is a statement about Figure’s engineering path, not proof that all tendon-driven hands are flawed.
1X NEO: a case for tendon-driven hands
1X states that NEO’s new hand has 25 force-controlled DOF: 22 across the fingers and palm and three at the wrist. It uses tendons and relatively low gear ratios, promoting backdrivability for contact with people and objects. The company also claims an IP68 hand rating and reports millions of cycles for individual tested components.
These are manufacturer claims. A component cycle count is not an independent endurance test of the complete robot performing household chores. A headline comparison of “25 versus 13” is especially misleading when one total includes wrist motion and the systems have not been assessed on identical loads, objects and success criteria.
Tendons versus direct drive: what actually matters?
Tendons can move larger motors toward the forearm and reduce moving mass at the hand. Their routing and tensioning, however, introduce maintenance considerations. Joint-mounted drives shorten the transmission path and may simplify modeling, but consume space and thermal capacity in the hand itself. Neither architecture wins without reference to a specific task and a tested implementation.
A credible benchmark would ask all four systems to grasp, reorient and use tools on the same randomized set of objects. It would disclose every attempt, autonomous versus teleoperated runs, acceptable error, cycle time, energy use and documented servicing. Edited video establishes that a behavior can be shown; it cannot substitute for those measurements.
Verdict: no proven all-round winner yet
Atlas prioritizes a four-finger tool hand, Figure combines palm-level vision with touch, and 1X pursues a highly articulated tendon system. Tesla’s currently relevant hand remains too loosely specified publicly for a fair four-way technical ranking. The decisive metric will be repeatable work in real environments, not a record DOF number. Until comparable endurance and success-rate data are available, any overall winner is a forecast rather than a finding.
Frequently asked questions
Does Atlas really have only four fingers?
Yes. Boston Dynamics describes three fingers plus a movable thumb, with 13 DOF overall. It intentionally omitted the pinky.
Does NEO’s 25 DOF make it better than Atlas’s 13?
Not by itself. The NEO total includes three wrist DOF, and the hands differ in actuation, sensing and intended jobs.
Which hand has proved itself in continuous operation?
The public sources reviewed here do not contain an independent, standardized long-duration comparison of all four current hands under the same conditions.
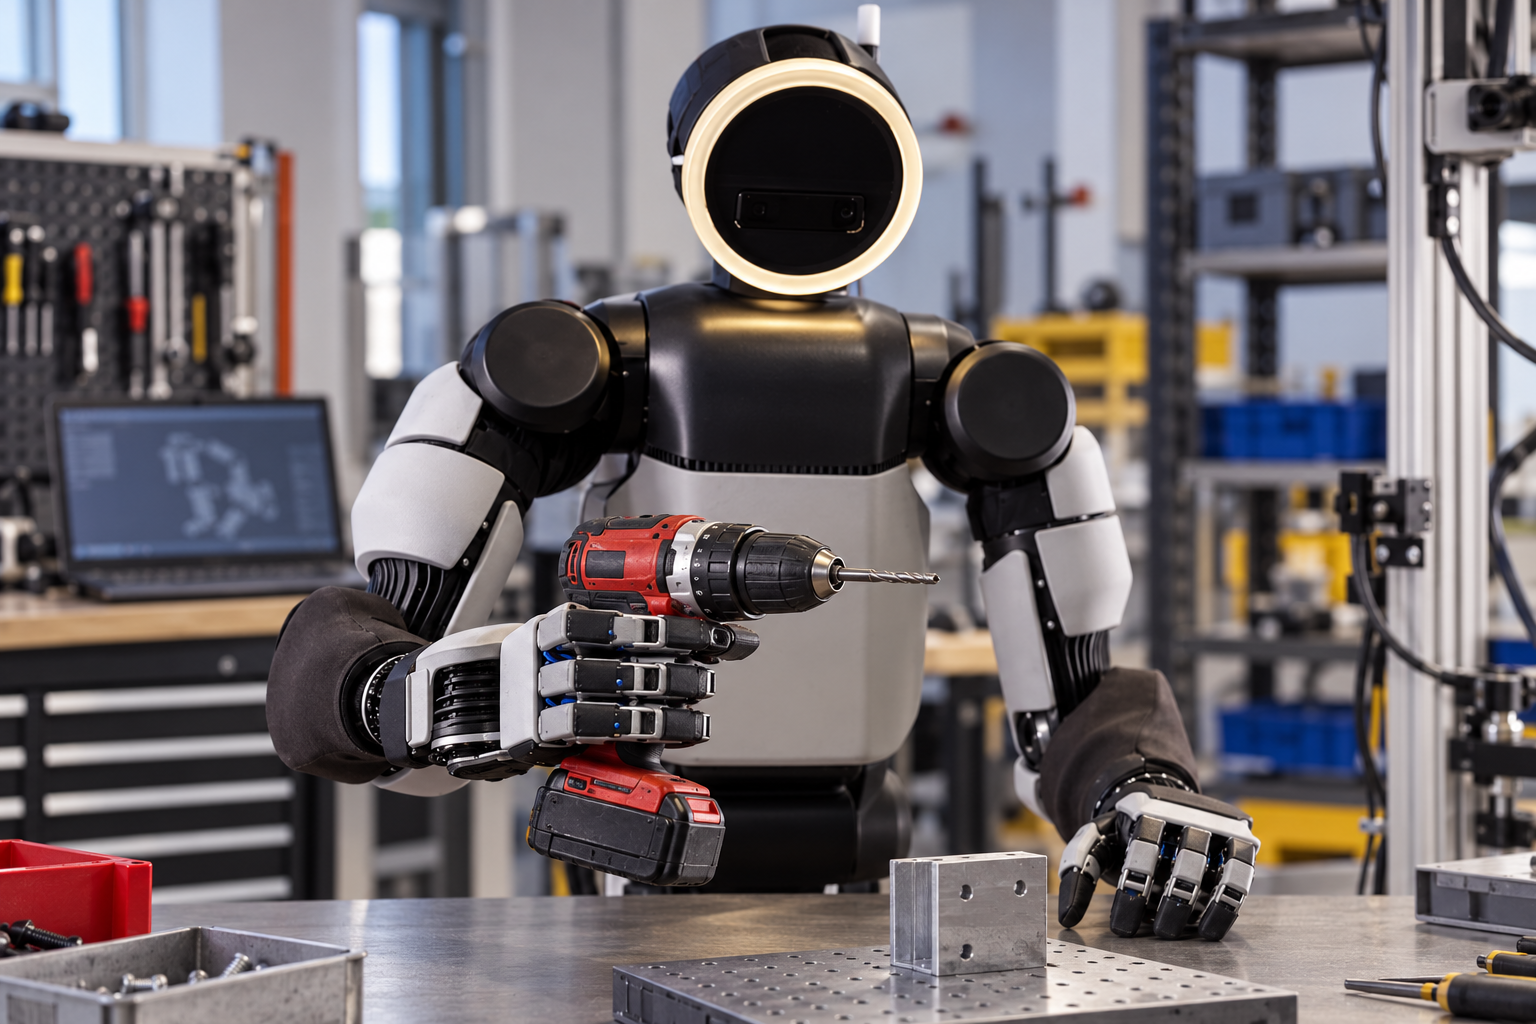
Featured image: AI-generated editorial illustration based on a visual reference of the real Atlas model; not a manufacturer photograph or documented test.
Sources
- Robot Uncut: comparative video
- Boston Dynamics: Robot Hands for Modern AI and Real Work
- Figure: Introducing Figure 03
- Figure: Helix 02
- 1X: NEO’s Hands
- Tesla: 2024 investor presentation
Author Nico Nuss has worked with mobile computing and automation software since 2001. His many years of experience and strong interest in emerging technologies shape his work on robotics and artificial intelligence.