Tesla has published a US patent application for flexible touch sensors that can conform to curved robotic surfaces. The proposed sensor arrays could cover fingers, a thumb or parts of a palm and register contact across multiple sensing points. That makes the idea relevant to dexterous robot hands. It does not, however, confirm a new Optimus hand, a production sensor or measured performance.
In this article
What does Tesla’s flexible touch-sensor patent application describe?
The application, US 2026/0310299 A1, was published on October 8, 2026. Tesla filed it on September 11, 2025, claiming priority to a provisional filing from April 4, 2025. Its title is “Three-Dimensional Soft Compliant Array Tactile Sensor with Multi-Modal Sensing and Scalable Manufacturing Methods.” A published application is a disclosure of an invention, not proof that a patent has been granted or that the technology is shipping.
The central idea is a soft, compliant sensor array shaped to follow a three-dimensional surface. Instead of placing a rigid flat sensor on a curved finger, the sensing layer can fit around the finger’s contour. Distributed sensing elements, often called taxels or tactile pixels, could help a controller identify where contact occurs. The application discusses both capacitive and resistive approaches rather than one proven final product configuration.
How could a robot hand sense touch?
In a capacitive design, pressure changes the relationship between conductive layers and therefore their electrical capacitance. In a resistive design, deformation changes electrical resistance. A controller can read many small sensing regions to create a map of contact across the hand. That map may help a robot adjust a grip when an object touches a fingertip or palm, but the patent application does not report a validated gripping benchmark.
There is an important distinction in the word “three-dimensional.” Here it chiefly describes the geometry of the sensor structure: the array is intended to conform to a non-flat surface. It does not, by itself, mean that every sensing point measures force independently along three axes. Assessing that would require specifications and test results for force direction, sensitivity, resolution, sampling speed and calibration.
Why is manufacturing the key part of this filing?
Tactile sensing in robot hands is not a new idea. The difficult part is making a thin sensing surface that can be manufactured consistently, placed on complex shapes and survive repeated contact. Tesla’s filing describes production routes including printing, molding and laser-based processes, as well as ways of forming layers directly on curved components. Those methods could matter if a hand needs many comparable sensor regions rather than a one-off laboratory prototype.
The application also discusses protective layers and integration into a compliant structure. Yet it gives no independently verified service-life figure for abrasion, grip cycles, sensor drift or field repairs. A plausible manufacturing route is therefore not the same as demonstrated mass-production yield or long-term reliability.
Is this already part of Tesla Optimus?
Not on the evidence in the published filing. It refers to robotic applications, but it does not identify an Optimus generation or confirm installation in a Tesla humanoid robot. It is reasonable to see the potential connection: a general-purpose humanoid needs to feel contact to grasp unfamiliar objects without excessive force. It would be speculation to present this patent application as proof of an announced Optimus upgrade.
| Supported by the filing | Not established by the filing |
|---|---|
| A flexible array intended for curved surfaces | Deployment in an Optimus production hand |
| Capacitive and resistive sensing variants | Measured tactile resolution or grip improvement |
| Several proposed manufacturing processes | Mass-production yield, durability or price |
The next meaningful evidence would be a demonstrable hand prototype, published measurements and repeatable manipulation tests. Until then, the filing is best read as an engineering proposal for tactile-sensor design and manufacture.
FAQ
Did Tesla patent a new Optimus hand?
Tesla published a US patent application concerning flexible tactile-sensor arrays. The document does not name Optimus or confirm a product release. An application also does not mean a patent has already been granted.
What is a tactile pixel?
It is one addressable sensing region in an array. Readings from multiple regions can show where contact occurs across a robotic surface.
Does “3D sensor” mean three-axis force measurement?
Not necessarily. In this filing, three-dimensional primarily refers to a sensor that follows a curved shape. Three-axis force capability would need separate evidence.
Sources: Tesla’s published US patent application and the Humanoids Daily report. This article is an independent editorial analysis.
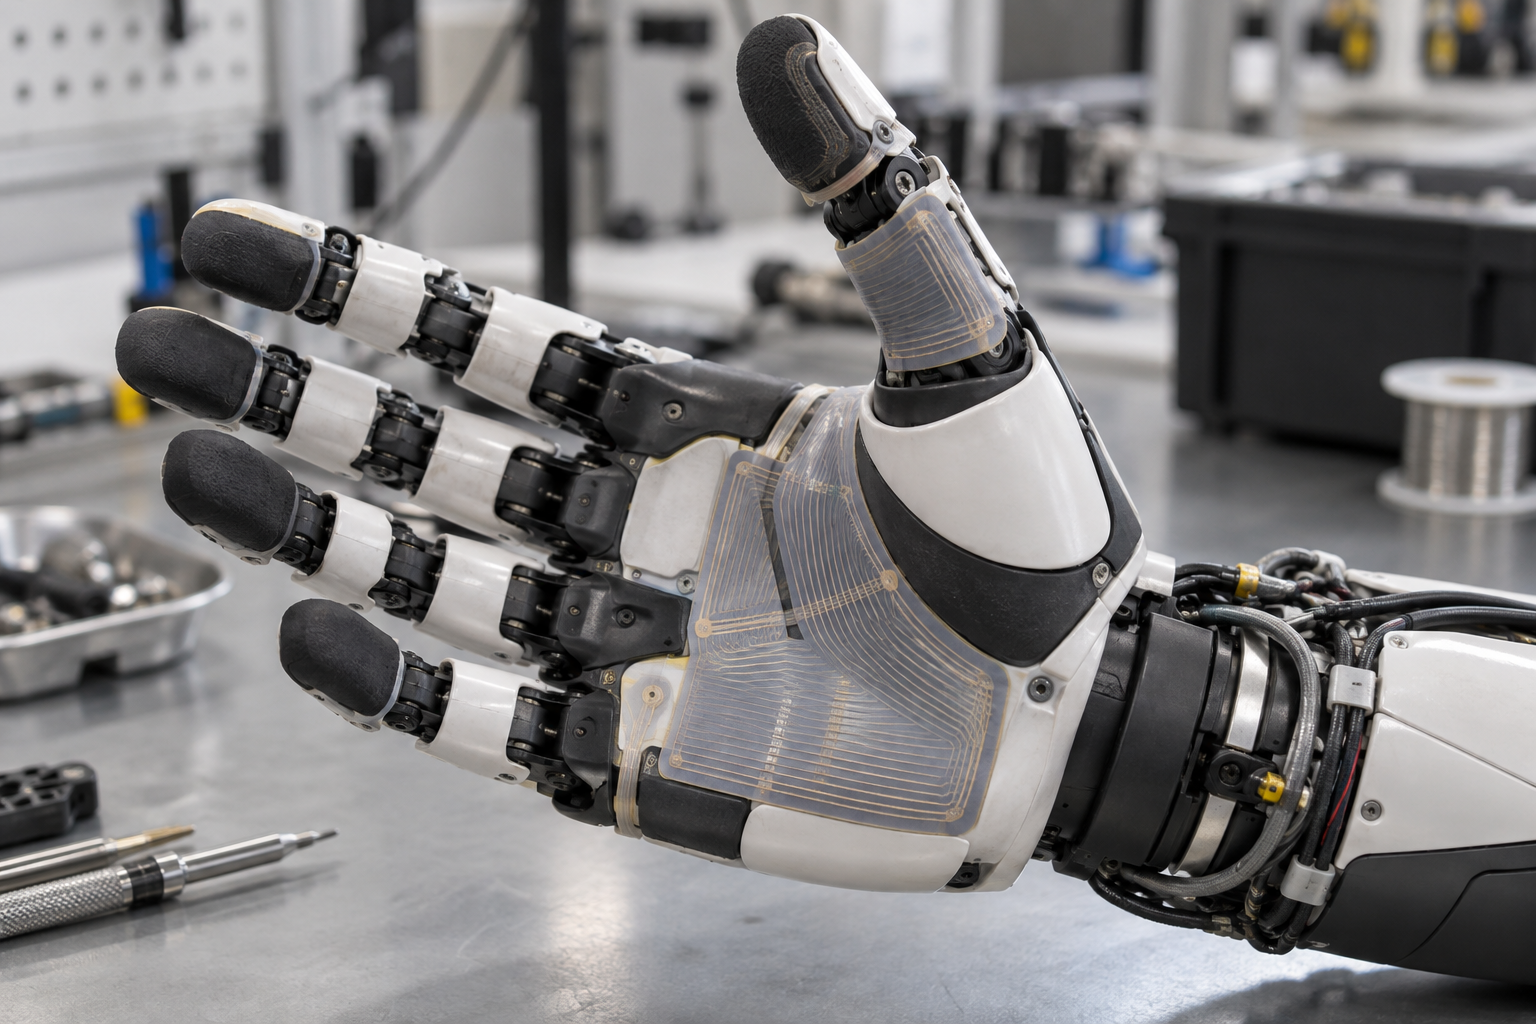
Featured image: editorial AI illustration of a mechanically plausible robot hand with tactile sensing patches; not a photograph of a Tesla or Optimus hand.
Author Nico Nuss has worked with mobile computing and automation software since 2001. His many years of experience and strong interest in emerging technologies shape his work on robotics and artificial intelligence.