A locomotion controller trained on one quadruped robot has been transferred to several different robot bodies without additional fine-tuning. The system, called Morphology-aware FiLM Critic or MorFiC, was developed by researchers at the University of Maryland and George Mason University. It addresses a stubborn robotics problem: a policy that works well on one machine often fails when leg length, mass distribution, joint range or motor strength changes.
The result is not a universal robot brain. MorFiC has been demonstrated on quadrupeds with related body plans, and the researchers report clear limits on heavier or substantially different machines. Even with that qualification, the work is important. Reusing locomotion skills across a product family could reduce training time, simulation effort and the cost of bringing new platforms into operation.
In this article
Why robot bodies normally need separate training
Learning-based locomotion policies connect sensor readings with motor commands. During training, the controller discovers how much torque to apply, when to lift each foot and how to correct a disturbance. Those decisions depend on the physical body. A longer leg changes leverage; a heavier torso changes inertia; different actuators respond at different speeds.
A policy can therefore become highly specialised. It may appear intelligent on the machine used in training while relying on timing and dynamics unique to that platform. Moving it to another robot can produce unstable steps, frozen behaviour or falls. The usual answer is to retrain or fine-tune the policy for every new body, often with a dedicated simulation model.
That approach works, but it weakens the promise of scalable embodied AI. Manufacturers and research groups operate multiple robot variants. If each one needs a separate training campaign, software reuse remains limited even when the machines perform the same basic task.
What MorFiC changes
MorFiC introduces information about morphology into the learning process. In simplified terms, the critic that evaluates behaviour is conditioned on the robot body. Feature-wise linear modulation, the “FiLM” in the name, helps the model adjust internal representations according to physical characteristics rather than treating every machine as identical.
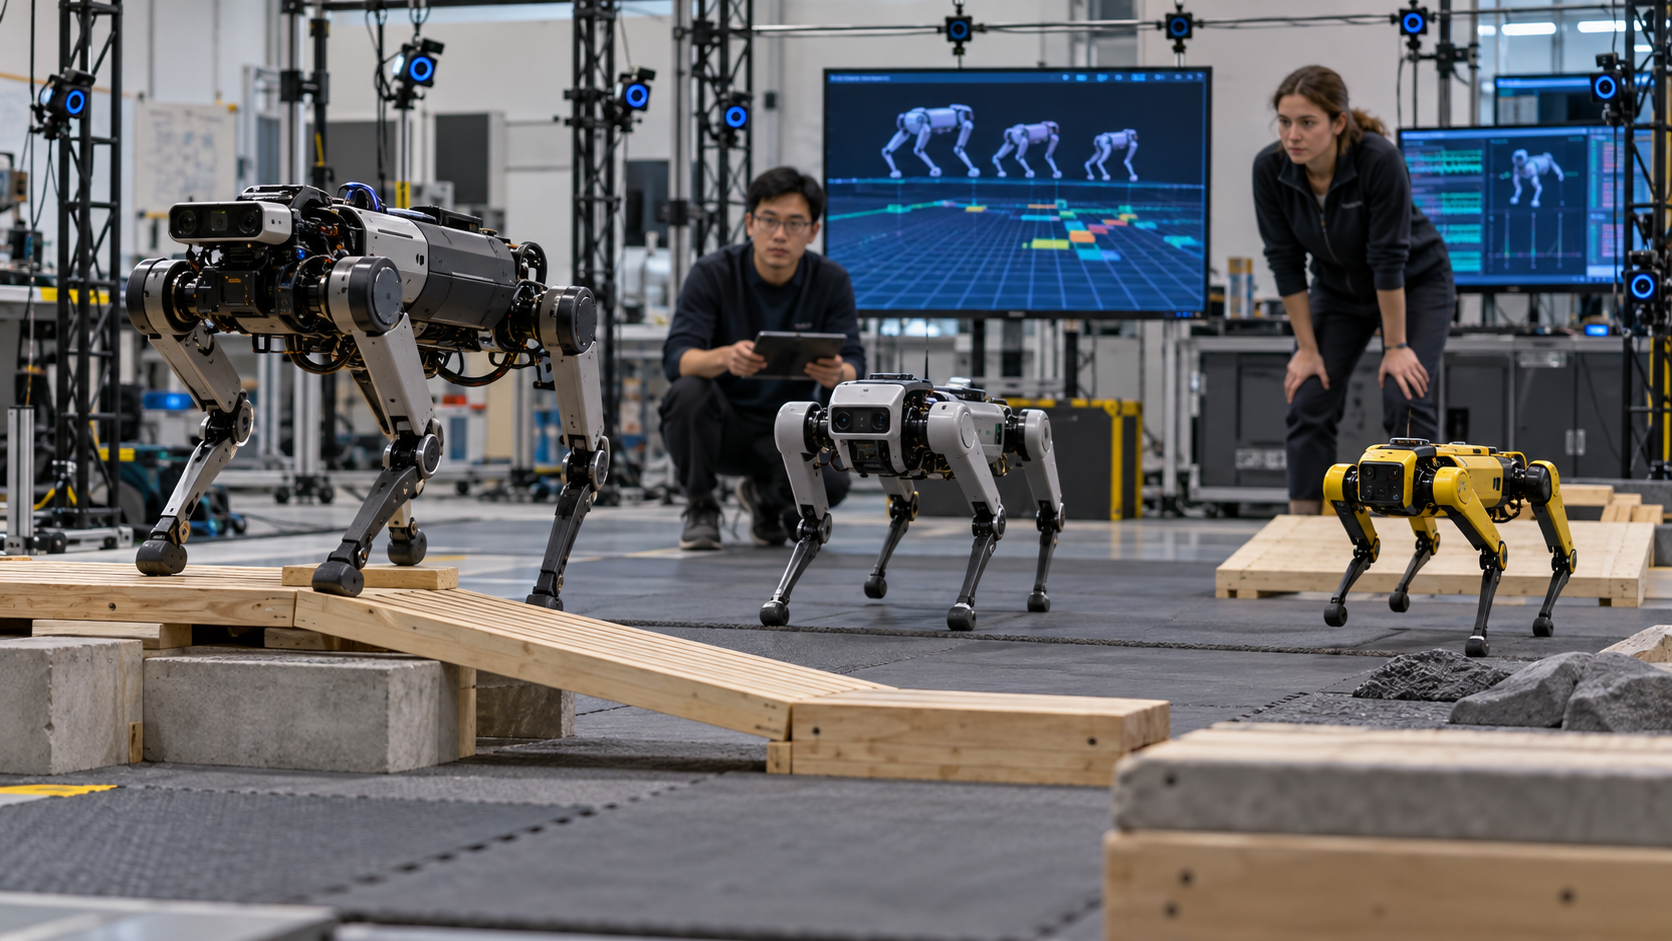
The researchers trained the system on a Unitree Go2 for roughly two hours. The resulting locomotion policy was then evaluated on other quadruped platforms. The paper describes zero-shot transfer: the policy was applied without a new round of task-specific fine-tuning on the target body.
In simulation, the authors tested seven platforms. The university’s report highlights an AlienGo result of 1.98 metres per second, while conventional comparison variants remained below 0.65 metres per second. Real-world tests included Go1 and Go2 robots. Reported Go1 speeds were around 1.4 to 1.7 metres per second, with more than 80 percent of runs avoiding freezing or gait failure. The Go2 achieved roughly 1.1 to 1.3 metres per second in the cited tests.
What “zero-shot” does and does not mean
Zero-shot transfer is an attractive phrase, but it needs careful interpretation. It means the target robot did not receive the usual additional policy optimisation for that specific deployment. It does not mean the system had no information about robot morphology, ignored physical constraints or can operate any machine ever built.
The controller still relies on a family of related locomotion problems and on observations that can be mapped between platforms. The robots are all quadrupeds with recognisable similarities in joints and gait. Moving from one four-legged platform to another is a meaningful challenge, but it is different from transferring the same policy to a humanoid, a wheeled manipulator or a six-legged inspection robot.
This distinction is essential for evaluating the claim. MorFiC improves generalisation inside a relevant class of machines. It does not erase the relationship between software and body.
The failures are as informative as the successes
The paper reports that the policy did not produce effective motion on the heavier Unitree B1 and on ANYmal, whose morphology differs more strongly from the training platform. These results prevent the story from becoming another claim of limitless general intelligence. They also indicate where future work is needed.
Mass and actuator capability change the feasible action space. A controller that expects a lightweight leg to accelerate quickly may command movements that a heavier mechanism cannot follow. Differences in joint orientation or body proportions can make a familiar gait mechanically inappropriate. Software can compensate only when the observation and action interfaces still contain enough shared structure.
For industrial users, such boundaries are not a weakness to hide. They are part of defining a safe operating envelope. A transferable controller should identify when a target body falls outside that envelope instead of attempting unstable behaviour.
Why this matters beyond robot dogs
Quadrupeds are useful test platforms because they combine dynamic balance with commercial relevance. They are considered for inspection, mapping, public safety and work in environments built for people but unsuitable for wheels. Fleets may include different sizes or hardware generations. A reusable locomotion layer could simplify updates across those fleets.
The broader idea also matters for humanoids. Humanoid companies are developing families of machines with different dimensions and payloads. Training every model from the beginning is expensive. A method that conditions control on morphology could eventually help a skill survive hardware revisions. The current work does not demonstrate that leap, but it shows a concrete path to studying it.
Transferable control could also improve simulation workflows. Instead of building one perfectly tuned policy per digital twin, engineers might train a more general policy on a distribution of physical characteristics. That can reduce sensitivity to small modelling errors when the controller moves from simulation to a real robot.
Questions that still need answers
Speed is only one measure of locomotion quality. Long-term deployment requires energy efficiency, recovery after slips, performance on irregular surfaces, actuator temperature and predictable stopping. The reported experiments establish transfer and useful movement, but they do not yet prove all-day field reliability.
It will also be important to see whether the method handles payload changes. A robot carrying a sensor mast or tools can have very different dynamics from the same robot when unloaded. Another question is how much morphology information must be known in advance and how accurately it must describe a target machine.
Finally, safety mechanisms must remain independent of the learned policy. Joint limits, contact detection and emergency stops should not depend on a controller generalising correctly. Transfer is valuable only when failure is contained.
The Alpha Bionic view
MorFiC is best understood as progress toward portable robot skills, not as a universal intelligence. Its strongest contribution is practical: it reduces the amount of retraining needed when the body changes within a related group. That makes the software layer more reusable while keeping physical differences visible.
The honest limits strengthen the result. The unsuccessful B1 and ANYmal tests reveal where similarity ends and where new methods are required. For robotics buyers and developers, that is more useful than a flawless demo reel. The next milestone is not a faster single run, but robust transfer across payloads, terrain and longer operating periods with clear confidence limits.
Sources
- University of Maryland: One Robot, Many Bodies, 18 September 2026
- MorFiC research paper on arXiv, revised 24 August 2026 and accepted at CoRL 2026